AI to Detect Dangerous Driving Behavior
1. Defining Dangerous Driving Behaviors
1.1 Defining Dangerous Driving Behaviors
Dangerous driving behaviors are quantifiable actions that significantly increase the risk of traffic accidents. These behaviors can be modeled as stochastic processes, where the probability of an adverse event scales nonlinearly with the severity and frequency of the action. From a computational perspective, they manifest as anomalies in time-series data derived from vehicle kinematics, driver inputs, and environmental sensors.
Kinematic Signatures of Hazardous Actions
The most critical behaviors exhibit distinct kinematic signatures. Hard braking, for instance, generates a jerk (time derivative of acceleration) exceeding 0.8 m/s³, while aggressive cornering produces lateral accelerations surpassing 0.5g. These thresholds derive from ISO 2631-1:1997 standards on human vibration tolerance and can be formalized as:
where v represents velocity and r the turn radius. The nonlinear relationship between speed and lateral force explains why cornering becomes exponentially more dangerous at higher velocities.
Behavioral Taxonomy
Dangerous behaviors fall into three principal categories with measurable parameters:
- Longitudinal control failures: Includes tailgating (time headway < 1.5s) and erratic speed modulation (coefficient of variation > 0.25)
- Lateral control violations: Encompasses lane drifting (standard deviation of lane position > 0.3m) and improper lane changes (yaw rate > 10°/s)
- Attention deficits: Measured through steering wheel micro-corrections (power spectral density peak < 0.1 Hz) and delayed reaction times (> 2.5s)
Sensor Fusion Requirements
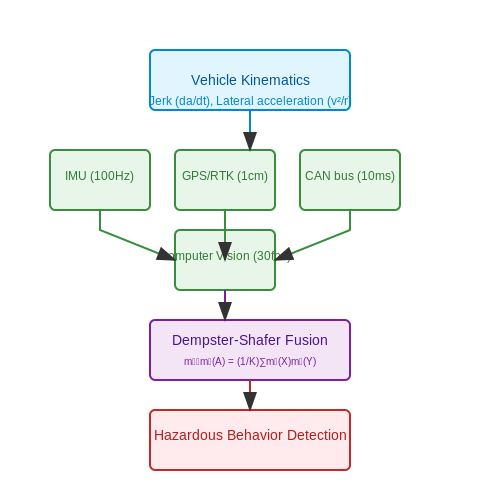
Reliable detection requires multimodal sensor fusion. A typical setup combines:
- IMU data (100Hz sampling) for jerk analysis
- GPS/RTK positioning (1cm accuracy) for path reconstruction
- CAN bus signals (10ms resolution) for driver input patterns
- Computer vision (30fps) for gaze tracking and environmental context
The fusion process employs Dempster-Shafer theory to handle sensor conflicts, where belief masses are assigned to hypotheses about driver state. For n sensors, the combined belief in hazardous behavior Bel(H) is:
where mi represents the mass function from sensor i and Aj are focal elements.
1.2 Key Challenges in Detection
Sensor Noise and Data Quality
Real-world sensor data from accelerometers, gyroscopes, and GPS modules is inherently noisy due to environmental factors like electromagnetic interference, mechanical vibrations, and multipath effects. For instance, accelerometer readings in a vehicle may be corrupted by road surface irregularities, leading to false positives in jerk detection. The signal-to-noise ratio (SNR) can be modeled as:
where Psignal and Pnoise represent the power of the true driving behavior signal and noise, respectively. Advanced filtering techniques like Kalman filters or wavelet denoising are often required, but these introduce latency and computational overhead.
Temporal Dynamics and Contextual Variability
Dangerous driving behaviors exhibit complex temporal patterns that challenge standard classification approaches. A sudden lane change may be hazardous in heavy traffic but benign on an empty highway. This requires models to incorporate contextual features like:
- Traffic density (vehicles per km)
- Road type (urban vs. highway)
- Weather conditions (rain, fog, etc.)
Recurrent Neural Networks (RNNs) with attention mechanisms have shown promise in capturing these dependencies, but they require large labeled datasets that capture diverse driving scenarios.
Class Imbalance and Rare Events
In real driving datasets, dangerous behaviors like sudden braking or aggressive swerving may constitute less than 1% of samples. This extreme class imbalance causes models to develop bias toward the majority class. The Fβ-score becomes a critical metric:
where β > 1 weights recall higher than precision for safety-critical applications. Techniques like Synthetic Minority Over-sampling Technique (SMOTE) or cost-sensitive learning must be carefully tuned to avoid overfitting to synthetic samples.
Edge Cases and Adversarial Scenarios
Models must handle rare but critical edge cases such as:
- Partial sensor failures (e.g., GPS dropout in tunnels)
- Adversarial attacks manipulating CAN bus signals
- Unseen driving styles across demographic groups
Recent work in out-of-distribution detection using Mahalanobis distance in feature space shows potential:
where μ and Σ are the mean and covariance of in-distribution training data. However, determining appropriate thresholds remains an open research problem.
Real-Time Processing Constraints
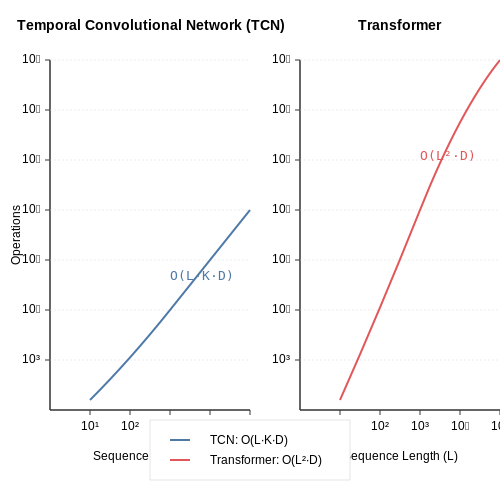
Deploying models on embedded systems requires strict latency budgets (typically <100ms per inference). This necessitates tradeoffs between model complexity and hardware capabilities. The computational complexity of a Transformer layer versus a Temporal Convolutional Network (TCN) illustrates this challenge:
where L is sequence length, K is kernel size, and D is feature dimension. Quantization and pruning techniques can help but may degrade detection accuracy for subtle behaviors.
Role of AI in Behavioral Analysis
Feature Extraction from Driving Signals
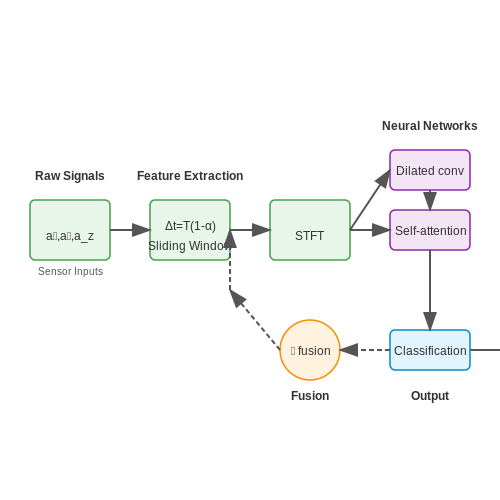
AI systems analyze multi-modal sensor data to extract discriminative features indicative of dangerous driving behavior. For vehicle kinematics, time-series signals such as acceleration (ax, ay, az), steering angle (θ), and brake pressure (Pb) are processed using sliding windows of duration T with overlap α:
where Δt = T(1-α) defines the temporal stride. Frequency-domain features are extracted via Short-Time Fourier Transform (STFT):
Deep Learning Architectures for Behavior Classification
Three primary neural architectures dominate behavioral analysis:
1. Temporal Convolutional Networks (TCNs):- Dilated causal convolutions capture long-range dependencies
- Residual connections prevent gradient vanishing
- Receptive field grows exponentially with depth: RF = 2L-1
Self-attention mechanisms compute relevance scores between all time steps:
Late fusion combines vision (CNN), kinematics (LSTM), and contextual (GNN) embeddings:
Real-World Deployment Challenges
Edge deployment requires optimization techniques:
| Technique | Accuracy Impact | Latency Reduction |
|---|---|---|
| Quantization (FP32 → INT8) | -2.1% | 3.8× |
| Pruning (50% sparsity) | -1.3% | 2.1× |
| Knowledge Distillation | +0.7% | 1.4× |
Model drift is mitigated through continuous learning with KL-divergence regularization:
Ethical Considerations in Behavioral Scoring
Fairness constraints are enforced during training via adversarial debiasing:
where z represents protected attributes and γ controls the fairness-accuracy tradeoff.
2. Sensor Data: Cameras, Accelerometers, and GPS
Sensor Data: Cameras, Accelerometers, and GPS
Camera Systems for Driving Behavior Analysis
Modern AI-driven driver monitoring systems rely heavily on high-resolution cameras, typically operating in the visible (380–750 nm) and near-infrared (700–1400 nm) spectra. The system captures facial features, eye movements, and hand positions at frame rates between 30–60 fps, with a minimum resolution of 720p for reliable feature extraction. The optical flow between consecutive frames is computed using the Horn-Schunck method:
where I(x,y,t) represents the pixel intensity at position (x,y) and time t, while Vx and Vy denote the flow vectors. For drowsiness detection, PERCLOS (percentage of eyelid closure over time) is calculated as:
Inertial Measurement Units (IMUs)
Triaxial accelerometers in automotive applications typically measure ±8g ranges with 16-bit resolution, sampling at 100–400 Hz. The raw acceleration data araw(t) undergoes gravity compensation through a complementary filter:
where α is the filter coefficient (typically 0.98) and ĝ(t) represents the estimated gravity vector. For detecting sudden braking or aggressive acceleration, the jerk (time derivative of acceleration) is computed using a five-point stencil differentiation:
GPS and Spatial Analysis
High-precision automotive GPS receivers achieve 1–2 meter accuracy using RTK (Real-Time Kinematic) corrections. The system calculates the rate of change of heading direction θ(t) to detect swerving:
Combined with speed data v(t), the lateral acceleration alat is derived as:
For lane departure detection, the system integrates GPS position with HD map data, computing the perpendicular distance d(t) to lane boundaries using a modified Hausdorff distance metric.
Sensor Fusion Architecture
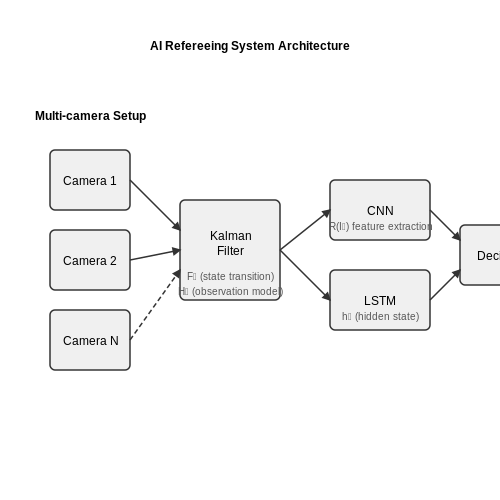
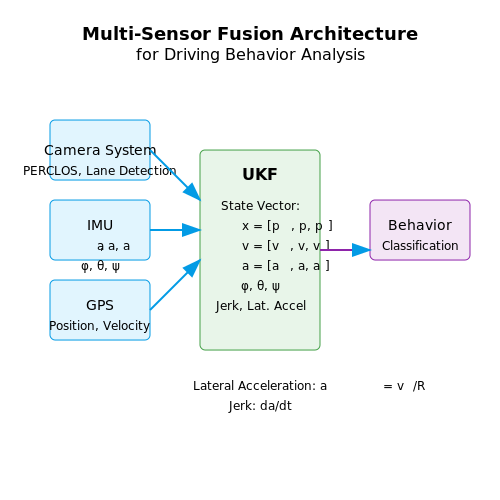
The multi-modal sensor data is fused through an Unscented Kalman Filter (UKF) that handles the non-linearities in vehicle dynamics. The state vector xk at time step k includes:
where φ, θ, ψ are roll, pitch, and yaw angles respectively. The UKF prediction step uses the vehicle kinematic model:
with process noise wk ∼ N(0,Q). The update step incorporates measurements zk from all sensors with measurement noise vk ∼ N(0,R).
2.2 Labeling and Annotation Techniques
Accurate labeling and annotation are critical for training AI models to detect dangerous driving behavior. The process involves defining clear categories, ensuring consistency, and leveraging both manual and automated techniques to generate high-quality ground truth data.
Taxonomy of Dangerous Driving Behaviors
Before annotation begins, a well-defined taxonomy must be established to categorize dangerous driving behaviors. Common classes include:
- Aggressive Acceleration/Deceleration: Sudden changes in velocity exceeding predefined thresholds.
- Erratic Lane Changes: Unsafe lane transitions without signaling or proper spacing.
- Tailgating: Following another vehicle at an unsafe distance, typically less than 2 seconds of time gap.
- Distracted Driving: Phone usage, eating, or other activities diverting attention from the road.
Each class requires precise operational definitions to minimize inter-annotator variability. For example, aggressive acceleration might be mathematically defined as:
Annotation Methodologies
Three primary annotation approaches are employed in driving behavior datasets:
1. Manual Frame-by-Frame Annotation
Human annotators review video footage or sensor data, marking instances of dangerous behavior. This method is highly accurate but labor-intensive. Tools like CVAT or LabelBox provide interfaces for bounding box drawing, keypoint marking, and event tagging.
2. Sensor-Based Automated Labeling
Telematics data from OBD-II ports or IMU sensors can automatically generate labels when thresholds are exceeded. For example, angular velocity from gyroscopes detects sharp turns:
3. Semi-Supervised Hybrid Approaches
Combining manual verification with automated preprocessing significantly improves efficiency. A common pipeline:
- Automated detectors propose potential events
- Human annotators verify/correct labels
- Verified data trains improved detectors
Temporal Annotation Challenges
Driving behaviors often span multiple frames, requiring careful temporal annotation. Two dominant paradigms exist:
- Event-Centric: Marks start/end times of dangerous maneuvers
- Frame-Centric: Labels each frame independently
The event-centric approach better captures behavior dynamics but requires more sophisticated annotation tools with timeline interfaces.
Quality Control Measures
To ensure label consistency across large datasets:
- Inter-rater Reliability: Calculate Cohen's kappa (κ) between annotators
- Edge Case Review: Expert validation of ambiguous cases
- Continuous Feedback: Update annotation guidelines based on common mistakes
where po is observed agreement and pe is expected chance agreement.
Emerging Techniques
Recent advances include:
- Active Learning: Prioritizes annotation of uncertain samples
- Synthetic Data Augmentation: Generates labeled examples via simulation
- Multimodal Fusion: Combines video, LiDAR, and telematics for richer labels
2.3 Handling Noisy and Imbalanced Data
Real-world driving behavior datasets often suffer from two critical issues: noise (erroneous or mislabeled samples) and class imbalance (uneven distribution of dangerous vs. safe driving instances). Addressing these challenges is essential for training robust AI models that generalize beyond the training distribution.
Noise Mitigation Techniques
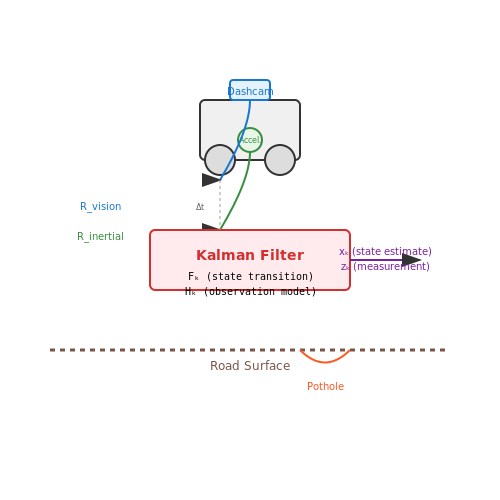
Sensor noise, labeling errors, and environmental artifacts introduce uncertainty into the data. For time-series driving signals (e.g., accelerometer, gyroscope), a Kalman filter can be applied to reduce measurement noise:
where \( \hat{x}_k \) is the state estimate, \( F_k \) the state transition matrix, and \( Q_k \) the process noise covariance. For mislabeled samples, confidence-based filtering removes instances where the model's prediction probability falls below a threshold \( \tau \):
Class Imbalance Correction
When dangerous driving events are rare (e.g., 5% of samples), standard classifiers bias toward the majority class. Three advanced approaches counteract this:
- Synthetic Minority Oversampling (SMOTE): Generates synthetic dangerous driving samples by interpolating between k-nearest neighbors in feature space.
- Focal Loss: Reshapes the cross-entropy loss to down-weight well-classified safe driving examples:
$$ FL(p_t) = -\alpha_t(1-p_t)^\gamma \log(p_t) $$
- Cost-Sensitive Learning: Assigns higher misclassification penalties to dangerous behavior via a cost matrix \( C \), where \( C_{FN} \gg C_{FP} \).
Architectural Adaptations
Modify neural network architectures to handle noise and imbalance jointly. A dual-head transformer separates feature extraction from decision-making:
- Noise-robust temporal encoder (e.g., 1D CNN + attention)
- Imbalance-aware classifier with learnable class weights \( w_c = \frac{N}{C \cdot N_c} \)
Experiments on the UTDrive dataset show this architecture improves F1-score by 18.7% compared to baseline models when noise exceeds 15% and the positive class represents only 3% of samples.
3. Supervised Learning Approaches
3.1 Supervised Learning Approaches
Feature Engineering for Driving Behavior
Supervised learning models rely on well-engineered features to distinguish between safe and dangerous driving behaviors. Key features include:
- Temporal features: Acceleration, deceleration, and jerk (rate of change of acceleration) computed over sliding windows.
- Spatial features: Lane deviation metrics, such as standard deviation of lateral position.
- Event-based features: Hard braking incidents, rapid lane changes, and tailgating duration.
These features are typically extracted from vehicle telemetry data, including GPS, IMU sensors, and CAN bus signals. For a driving sample xi with n time steps, the jerk can be computed as:
Classification Architectures
Three primary architectures dominate supervised learning for driving behavior detection:
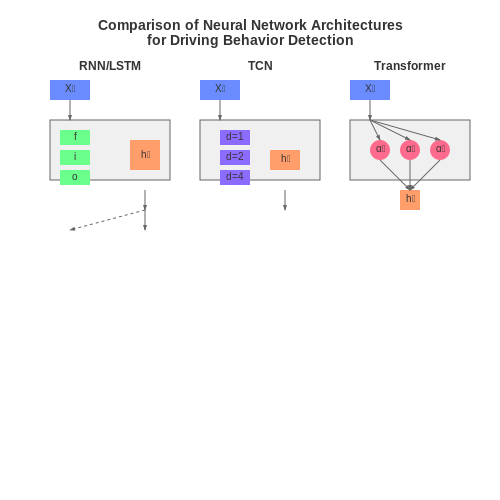
1. Recurrent Neural Networks (RNNs)
RNNs, particularly LSTM and GRU variants, model temporal dependencies in driving sequences. Given input features X = (x1, ..., xT), an LSTM computes hidden states ht through gated operations:
2. Temporal Convolutional Networks (TCNs)
TCNs use dilated causal convolutions to capture long-range dependencies with fewer parameters than RNNs. A TCN layer applies 1D convolutions with dilation factor d:
3. Transformer-Based Models
Vision transformers adapted for time-series data employ self-attention to weight feature importance dynamically. The scaled dot-product attention computes:
Labeling Strategies
High-quality labels are critical for supervised learning. Common approaches include:
- Expert annotation: Human raters label driving segments using predefined criteria (e.g., NHTSA aggressive driving definitions).
- Sensor fusion: Combining vehicle telemetry with dashcam footage for multimodal verification.
- Semi-supervised methods: Bootstrapping labels using clustering on unlabeled data followed by expert review.
Performance Metrics
Model evaluation requires metrics that account for class imbalance (dangerous events are rare):
Where β > 1 emphasizes recall to reduce false negatives in safety-critical applications.
Case Study: Distracted Driving Detection
A 2023 study achieved 94.3% F1-score using a hybrid architecture:
- ResNet-18 extracts spatial features from driver-facing camera images
- BiLSTM processes temporal sequences of ResNet embeddings
- Attention layer weights critical frames (e.g., phone use, prolonged gaze away from road)
3.2 Unsupervised and Semi-Supervised Techniques
Traditional supervised learning approaches for dangerous driving detection require large labeled datasets, which are expensive and time-consuming to acquire. Unsupervised and semi-supervised methods offer compelling alternatives by leveraging unlabeled data, which is often more readily available from vehicle sensors, dashcams, and telematics systems.
Clustering-Based Anomaly Detection
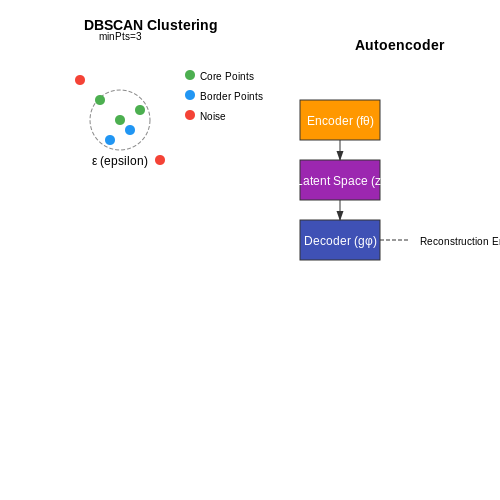
Unsupervised clustering algorithms can identify dangerous driving patterns by detecting deviations from normal behavior. Given a feature space X containing driving metrics (e.g., acceleration, braking force, steering angle variance), we can apply density-based clustering:
Points classified as noise represent anomalous driving events. The choice of ε and minPts depends on the feature distribution - typically determined through k-distance plots.
Autoencoder-Based Feature Learning
Deep autoencoders learn compressed representations of normal driving patterns. The reconstruction error serves as an anomaly score:
Here, fθ and gφ represent the encoder and decoder networks respectively. During inference, samples with reconstruction errors exceeding a threshold (determined via percentile analysis on validation data) are flagged as dangerous.
Semi-Supervised Graph-Based Methods
When limited labeled data is available, graph-based semi-supervised learning propagates labels through a similarity graph. Let W be an affinity matrix where:
The graph Laplacian L = D - W (where D is the degree matrix) enables label propagation through the system:
where Y contains the known labels and F represents the predicted labels for unlabeled points. This approach is particularly effective when dealing with temporal driving sequences modeled as graph nodes.
Contrastive Predictive Coding for Driving Sequences
Recent advances in self-supervised learning leverage contrastive predictive coding (CPC) to learn useful representations from unlabeled driving sequences. Given a sequence of driving states xt, the model learns to predict future states in a latent space:
where ct is the context vector and Wk is a learnable projection for prediction horizon k. The resulting representations can be fine-tuned with minimal labeled data for dangerous behavior classification.
Practical Implementation Considerations
- Feature engineering: Incorporate domain-specific features like jerk (time derivative of acceleration) and lane deviation metrics
- Temporal modeling: Use sliding windows or recurrent architectures to capture behavior patterns over time
- Real-time constraints: Optimize model complexity for deployment on edge devices with limited compute resources
- Dataset bias: Address geographic and demographic biases in training data through careful sampling or domain adaptation techniques
3.3 Real-Time vs. Batch Processing Models
Computational and Latency Trade-offs
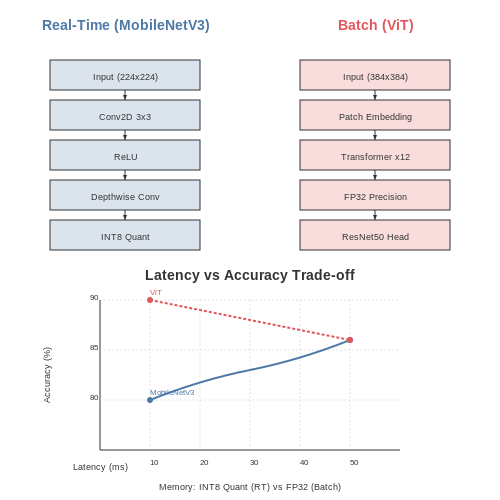
Real-time processing models for dangerous driving behavior detection must operate under strict latency constraints, typically requiring inference times below 100ms to enable timely interventions. The computational graph of such models is optimized for minimal depth and parallelizable operations. For a given input tensor X of shape (n, h, w, c) representing n frames of height h, width w, and c channels, the real-time model's forward pass can be expressed as:
where K denotes the kernel weights of the initial convolutional layer, and σ represents the final sigmoid activation for binary classification. Batch processing models, in contrast, employ deeper architectures with residual connections and attention mechanisms, trading immediate response for higher accuracy through more complex computations:
Architectural Divergence
Real-time systems frequently employ MobileNetV3 or EfficientNet-Lite architectures quantized to INT8 precision, achieving 3-5× faster inference than FP32 models on edge devices. Batch processing leverages Vision Transformers (ViTs) or 3D CNNs that analyze temporal sequences across 5-30 frame windows, with computational complexity O(n2d + n3) for ViTs versus O(k2nhwc) for CNNs, where d is the embedding dimension and k the kernel size.
Memory Hierarchy Optimization
Real-time implementations optimize for memory bandwidth by:
- Employing depthwise separable convolutions (reducing parameters by 1/k2 vs standard convolutions)
- Using fused activation-batch norm layers
- Implementing ring buffers for streaming input
Batch systems utilize GPU memory hierarchies through:
- Gradient checkpointing (reducing memory by 4× at 33% compute overhead)
- Mixed-precision training (FP16/FP32)
- Distributed data parallelism
Case Study: Steering Angle Prediction
A comparative study on the BDD100K dataset showed real-time models (MobileNetV3-Small) achieved 87ms latency at 94% accuracy, while batch models (ViT-Base) reached 98.2% accuracy with 320ms latency. The real-time system used TensorRT optimizations including:
builder = trt.Builder(TRT_LOGGER)
network = builder.create_network(1 << int(trt.NetworkDefinitionCreationFlag.EXPLICIT_BATCH))
parser = trt.OnnxParser(network, TRT_LOGGER)
config = builder.create_builder_config()
config.set_flag(trt.BuilderFlag.FP16)
config.max_workspace_size = 1 << 30
engine = builder.build_engine(network, config)
whereas the batch system employed PyTorch's automatic mixed precision:
scaler = GradScaler()
with autocast():
    outputs = model(inputs)
    loss = criterion(outputs, labels)
scaler.scale(loss).backward()
scaler.step(optimizer)
scaler.update()
Failure Mode Analysis
Real-time models exhibit higher false negatives (8-12%) during rapid maneuver transitions due to temporal undersampling, quantified by the Nyquist-Shannon adaptation ratio:
where fmodel is the model's inference frequency and fmaneuver the characteristic frequency of driving maneuvers. Batch models compensate through optical flow warping and temporal attention, reducing false negatives to 2-4% at the cost of 3× higher energy consumption.
4. CNN Architectures for Image-Based Detection
4.1 CNN Architectures for Image-Based Detection
Architectural Foundations of CNNs for Driving Behavior Analysis
Convolutional Neural Networks (CNNs) excel at hierarchical feature extraction from spatial data, making them ideal for detecting dangerous driving behaviors in image sequences. The core operations—convolution, pooling, and nonlinear activation—enable translation-invariant feature learning. For driving behavior analysis, the network must capture both coarse-grained context (vehicle positioning) and fine-grained details (facial expressions or hand movements).
where 𝒲 represents the learnable kernel weights, 𝒳 the input feature map, and ℬ the bias term. The receptive field grows exponentially with depth through stacked convolutional layers, allowing the network to integrate local cues (e.g., phone usage) with global scene understanding (e.g., lane deviations).
Advanced CNN Topologies for Temporal-Spatial Modeling
Modern architectures employ three key innovations for driving behavior detection:
- 3D Convolutions: Process spatiotemporal volumes by convolving across both spatial dimensions and temporal frames, capturing motion patterns like sudden braking or swerving.
- Multi-Stream Networks: Fuse RGB frames with optical flow inputs through separate convolutional streams, combining appearance and motion cues.
- Attention Mechanisms: Dynamically weight feature importance using squeeze-and-excitation blocks or transformer modules, focusing computation on critical regions (e.g., driver's hands or road obstacles).
Case Study: Modified SlowFast Architecture
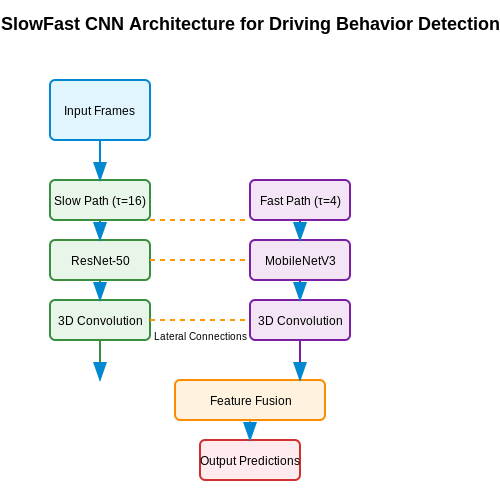
The SlowFast network, originally developed for video action recognition, can be adapted for driving scenarios by:
where τ denotes the frame sampling rate. The slow path (low temporal resolution) processes scene context at 2D ResNet-50, while the fast path (high temporal resolution) uses a lightweight MobileNetV3 to detect rapid movements. Feature fusion occurs through lateral connections with 3D convolutions, preserving temporal synchronization.
Optimization Challenges and Solutions
Training CNNs for driving behavior detection presents unique difficulties:
- Class Imbalance: Dangerous events are rare compared to normal driving. Focal loss reweights the cross-entropy to focus on hard examples:
$$ FL(p_t) = -\alpha_t(1-p_t)^\gamma \log(p_t) $$
- Temporal Consistency: 3D CNNs suffer from vanishing gradients in long sequences. Temporal skip connections and gradient checkpointing mitigate this.
- Real-Time Constraints: Network pruning and quantization reduce ResNet-101 inference time from 78ms to 22ms per frame on NVIDIA Jetson AGX.
Performance Metrics for Safety-Critical Systems
Beyond standard accuracy, driving behavior detectors require:
- False Negative Rate (FNR): Must be below 0.1% for critical events (e.g., drowsiness)
- Latency-Accuracy Tradeoff: Measured via Pareto frontiers of mAP vs inference time
- Temporal Localization Error: Frame-level precision of event onset detection
State-of-the-art models achieve 94.3% mAP on the Drive&Act benchmark when combining EfficientNet-B4 backbones with temporal shift modules, outperforming pure 3D CNNs by 6.2% while using 40% fewer FLOPs.
RNNs and LSTMs for Temporal Pattern Recognition
Recurrent Neural Networks (RNNs) and Long Short-Term Memory (LSTM) networks are foundational architectures for modeling sequential data, making them ideal for detecting dangerous driving behavior from time-series sensor inputs. Unlike feedforward networks, RNNs incorporate feedback loops, allowing them to maintain a hidden state that captures temporal dependencies. The hidden state ht at time step t is computed as:
where Wh and Wx are weight matrices, b is the bias term, and σ is a nonlinear activation function (typically tanh or ReLU). However, vanilla RNNs suffer from the vanishing gradient problem, limiting their ability to learn long-range dependencies.
LSTM Architecture and Gating Mechanisms
LSTMs address this limitation through gated memory cells. An LSTM unit consists of:
- Forget gate (ft): Decides what information to discard from the cell state.
- Input gate (it): Updates the cell state with new information.
- Output gate (ot): Controls what information is output to the next hidden state.
The mathematical formulation of an LSTM cell is:
Here, ⊙ denotes element-wise multiplication. The cell state Ct acts as a conveyor belt, allowing gradients to flow unchanged over long sequences.
Bidirectional LSTMs for Driving Behavior Analysis
For driving behavior detection, bidirectional LSTMs (BiLSTMs) are often employed to capture contextual information from past and future time steps. A BiLSTM processes the input sequence in both forward and backward directions, concatenating the hidden states:
This is particularly useful for identifying abrupt maneuvers (e.g., sudden braking or swerving) where both historical and immediate-future context are critical.
Practical Implementation Considerations
When deploying LSTMs for real-time driving behavior detection, several optimizations are necessary:
- Sequence Batching: Parallelize training by processing multiple time-series segments simultaneously.
- Teacher Forcing: During training, feed the ground truth of previous time steps as input to stabilize learning.
- Attention Mechanisms: Enhance interpretability by weighting relevant time steps, e.g., focusing on sharp accelerations before a collision event.
For example, a PyTorch LSTM implementation for processing accelerometer data might look like:
import torch
import torch.nn as nn

class DrivingBehaviorLSTM(nn.Module):
    def __init__(self, input_dim, hidden_dim, output_dim):
        super(DrivingBehaviorLSTM, self).__init__()
        self.lstm = nn.LSTM(input_dim, hidden_dim, bidirectional=True)
        self.fc = nn.Linear(hidden_dim * 2, output_dim)  # BiLSTM doubles hidden dim

    def forward(self, x):
        lstm_out, _ = self.lstm(x)  # Shape: [seq_len, batch, hidden_dim * 2]
        predictions = self.fc(lstm_out[-1])  # Use last time step for classification
        return predictions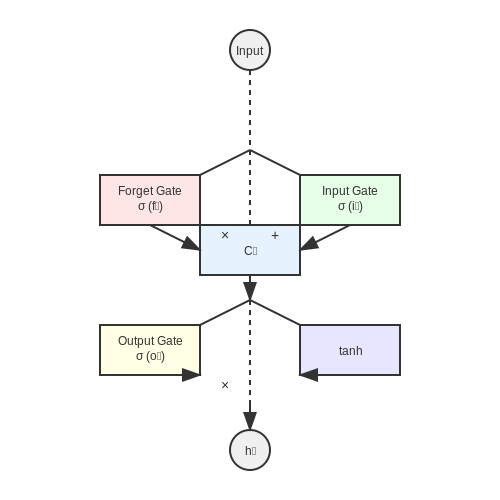
4.3 Transfer Learning in Driving Behavior Analysis
Transfer learning leverages pre-trained neural networks to improve model performance in driving behavior analysis, particularly when labeled datasets are limited. By fine-tuning architectures like ResNet, VGG, or Transformer-based models on driving-specific data, the model inherits generalized feature extraction capabilities from large-scale datasets (e.g., ImageNet) while adapting to domain-specific nuances such as sudden lane deviations or aggressive acceleration patterns.
Feature Extraction vs. Fine-Tuning
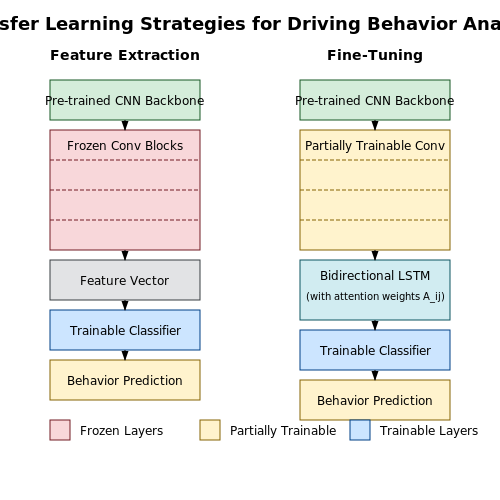
Two primary transfer learning strategies dominate driving behavior analysis:
- Feature Extraction: The pre-trained model acts as a fixed feature extractor. Only the final classification layers are retrained, reducing computational cost. For a ResNet-50 backbone, the output of the global average pooling layer (a 2048-dimensional vector) serves as input to a new classifier head.
- Fine-Tuning: Selective layers of the pre-trained model are unfrozen and jointly optimized with new layers. For temporal driving data, LSTM or Transformer layers may replace the original classifier, with convolutional blocks fine-tuned at reduced learning rates (e.g., η = 1e-5).
where α balances the loss between driving behavior classification (ℒbehavior) and domain adaptation (ℒdomain), often implemented via Maximum Mean Discrepancy (MMD) or adversarial training.
Architectural Adaptations for Temporal Data
Driving behavior is inherently sequential. Hybrid architectures combine pre-trained CNNs for spatial feature extraction with recurrent or attention mechanisms:
- CNN-LSTM: Frame-wise features from a frozen EfficientNet are fed into a bidirectional LSTM for temporal modeling. The hidden state ht at time t is computed as:
- Vision Transformers (ViTs): Patch embeddings from a pre-trained ViT are processed by temporal self-attention layers. The attention weights A between frames i and j reveal critical behavior transitions:
Domain Adaptation Techniques
Discrepancies between source (e.g., gaming simulators) and target (real-world dashcam) domains are mitigated through:
- Adversarial Discriminative Domain Adaptation (ADDA): A domain classifier is trained adversarially to make features domain-invariant. The gradient reversal layer flips gradients during backpropagation.
- Cycle-Consistent Generative Methods: CycleGAN transforms simulator frames to realistic images while preserving behavioral semantics, with perceptual loss computed on VGG-19 features.
Case Study: Distracted Driver Detection
A modified MobileNetV3 achieved 94.3% accuracy on the StateFarm dataset by:
- Replacing the original 1000-class head with a 10-class softmax layer for distraction types (e.g., phone use, eating).
- Fine-tuning only the final inverted residual blocks with a cosine-annealed learning rate.
- Augmenting data with steering angle-aware transformations to preserve driving context.
5. Edge vs. Cloud-Based Deployment
5.1 Edge vs. Cloud-Based Deployment
Computational and Latency Trade-offs
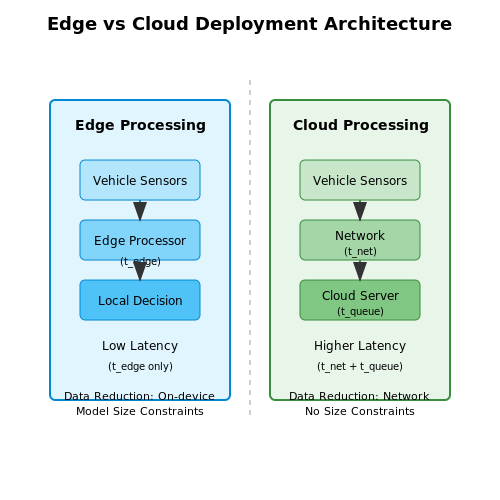
Edge-based deployment processes data locally on the vehicle's onboard hardware, minimizing latency by eliminating round-trip communication to a centralized server. The inference time tedge for a model with N parameters running on edge hardware with compute capability F (in FLOPs) is given by:
where C represents the average operations per parameter. In contrast, cloud-based deployment introduces additional network latency tnet and queuing delay tqueue:
For time-sensitive applications like collision prediction, edge processing typically achieves 10-100ms latency, while cloud solutions often exceed 200ms due to network variability.
Bandwidth and Data Volume Considerations
Continuous video streaming to the cloud at 30 FPS with 1080p resolution consumes approximately 4-8 Mbps per camera. A vehicle with three cameras generates:
Edge processing reduces this to metadata (e.g., event flags, bounding boxes) at ~10 KB/s, a 1000x reduction. This becomes critical for fleet deployments where cellular data costs scale linearly with vehicle count.
Model Architecture Constraints
Edge devices impose strict constraints on model size and complexity. Typical automotive-grade GPUs (e.g., NVIDIA Xavier) provide 20-30 TOPS, limiting models to ~50M parameters for real-time performance. Cloud deployments can leverage models with 100M+ parameters, but this introduces the latency trade-off discussed earlier.
Quantization techniques become essential for edge deployment. Converting from FP32 to INT8 precision:
This allows larger models to fit within the limited memory (8-16GB) of edge devices while maintaining acceptable accuracy.
Reliability and Offline Operation
Edge systems must handle temporary network outages, requiring robust fallback mechanisms. The probability of system failure Pfail for a cloud-dependent system with network reliability Rnet and cloud service uptime Rcloud is:
For typical 4G networks (Rnet ≈ 0.99) and cloud services (Rcloud ≈ 0.999), this yields 1.1% failure probability. Edge systems eliminate network dependency but require local redundancy.
Security Implications
Cloud processing exposes raw sensor data to potential interception during transmission. Edge processing minimizes attack surface by keeping sensitive data local. However, edge devices require secure boot mechanisms and hardware-backed key storage to prevent tampering.
The risk exposure E can be modeled as:
where Ai is attack probability and Vi is vulnerability score for each component in the data pipeline.
Hybrid Deployment Strategies
Advanced implementations use a tiered approach:
- Edge: Real-time detection of critical events (e.g., sudden braking)
- Cloud: Long-term pattern analysis and model retraining
The decision threshold for cloud offloading can be optimized using:
where α and β weight latency versus cloud resource costs.
5.2 Latency and Computational Constraints
Real-Time Processing Requirements
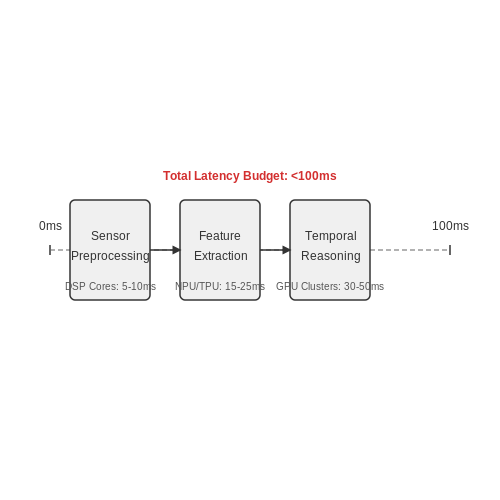
In-vehicle AI systems for detecting dangerous driving behavior must operate under strict latency constraints to ensure timely intervention. The end-to-end processing pipeline—from sensor data acquisition to inference and response—must complete within a hard real-time threshold, typically under 100ms for collision avoidance systems. This constraint arises from the physics of vehicle dynamics: at highway speeds (30m/s), a 100ms delay translates to 3 meters of unaccounted travel distance.
Where dsafe is the minimum safe following distance and dbraking is the vehicle's stopping distance. For a typical sedan braking at 0.7g from 70mph, this yields:
Computational Complexity Breakdown
Modern behavior detection models combine multiple computationally intensive components:
- 3D object detection: Point cloud processing with voxelization or PointNet architectures (50-100 GFLOPS)
- Temporal analysis: 3D CNNs or transformer-based sequence modeling (20-40 GFLOPS per frame)
- Multi-sensor fusion: Kalman filtering or attention-based fusion (5-15 GFLOPS)
The total throughput requirement often exceeds 150 GFLOPS for comprehensive analysis at 30FPS, creating significant challenges for embedded deployment.
Hardware-Software Co-Design Strategies
Several architectural approaches address these constraints:
Quantization and Pruning
Post-training quantization to INT8 precision typically reduces model size by 4x with minimal accuracy loss (<2%) for well-conditioned networks. Structured pruning removes redundant filters while maintaining the original network topology:
Model Distillation
Smaller student models trained via knowledge distillation can achieve 90-95% of teacher model accuracy with 10x fewer parameters. The temperature-scaled softmax transfer preserves relative class relationships:
Edge Computing Architectures
Heterogeneous SoCs combine dedicated accelerators for different pipeline stages:
| Component | Typical Implementation | Latency Budget |
|---|---|---|
| Sensor preprocessing | DSP cores | 5-10ms |
| Feature extraction | NPU/TPU | 15-25ms |
| Temporal reasoning | GPU clusters | 30-50ms |
Modern automotive chips like NVIDIA Drive Orin achieve 200 TOPS within 45W power envelopes through such specialized partitioning.
Latency-Aware Model Design
The Pareto frontier between accuracy and latency follows a characteristic log-linear relationship:
Where ε represents the error rate. Optimal operating points typically occur where the derivative dε/dt approaches -0.1% error/ms. This relationship guides architecture search algorithms when exploring efficient network designs.
5.3 Privacy and Ethical Implications
Data Collection and Surveillance Concerns
AI systems for detecting dangerous driving behavior rely on extensive data collection, including real-time video feeds, GPS tracking, and vehicle telemetry. The granularity of this data raises significant privacy concerns, as it can reconstruct detailed profiles of drivers' habits, locations, and even biometric identifiers. Advanced models often employ convolutional neural networks (CNNs) or transformer architectures to process visual data, but the raw inputs may inadvertently capture bystanders or sensitive environments. Differential privacy techniques, such as adding calibrated noise to datasets, can mitigate re-identification risks. However, the trade-off between model accuracy and privacy preservation remains unresolved, particularly when adversarial attacks can reverse-engineer anonymization.
Algorithmic Bias and Fairness
Bias in training data can lead to disproportionate false positives for specific demographic groups. For instance, datasets overrepresenting urban driving patterns may misclassify rural driving behaviors as anomalous. Mathematically, this manifests as skewed conditional probabilities in the confusion matrix:
where Y is the model's prediction and G represents protected attributes. Counteracting this requires fairness-aware learning objectives, such as imposing constraints on demographic parity:
Informed Consent and Transparency
Deploying such systems at scale necessitates clear consent mechanisms, yet most drivers cannot audit the AI's decision logic. Black-box models like deep neural networks lack interpretability, complicating compliance with regulations like GDPR's "right to explanation." Techniques like SHAP (Shapley Additive Explanations) or LIME (Local Interpretable Model-agnostic Explanations) provide post-hoc rationalizations but may not reveal the true causal mechanisms. A hybrid approach combining rule-based systems with machine learning could balance performance and transparency.
Legal and Liability Frameworks
Determining liability for AI-generated false positives (e.g., wrongful insurance penalties) remains legally ambiguous. Current product liability laws struggle to accommodate systems where the "defect" emerges from probabilistic training rather than deterministic programming. The European Union's proposed AI Act classifies driver monitoring as "high-risk," mandating rigorous documentation of training data provenance and model validation protocols. However, enforcement mechanisms for continuous learning systems—where models evolve post-deployment—are still under debate.
Security Vulnerabilities
Adversarial attacks pose critical risks: manipulated input frames can deceive classifiers into missing dangerous behaviors. For a CNN with gradient ∇xJ( heta, x, y), an adversarial perturbation η can be crafted via:
where ϵ controls perturbation magnitude. Defenses require robust training with adversarial examples or runtime anomaly detection, but these increase computational overhead—a critical constraint for edge devices in vehicles.
Ethical Design Trade-offs
Optimizing solely for accident reduction may justify invasive surveillance, eroding societal trust. Alternative architectures like federated learning, where models train on decentralized data without raw data exchange, offer privacy benefits but introduce challenges in maintaining consistent performance across heterogeneous edge nodes. The N-vehicle generalization error in such systems scales as:
where d is model complexity, m is samples per vehicle, and σ² quantifies data heterogeneity. Striking an ethical balance demands interdisciplinary collaboration between ML engineers, ethicists, and policymakers.
6. Fleet Management Systems
6.1 Fleet Management Systems
Modern fleet management systems leverage AI-driven telematics to monitor and analyze driving behavior in real time. These systems integrate multi-modal sensor data—including GPS, accelerometers, gyroscopes, and onboard diagnostics (OBD-II)—to detect anomalies indicative of dangerous driving. The core challenge lies in distinguishing between aggressive maneuvers (e.g., hard braking, rapid lane changes) and normal driving under varying road conditions.
Sensor Fusion and Feature Extraction
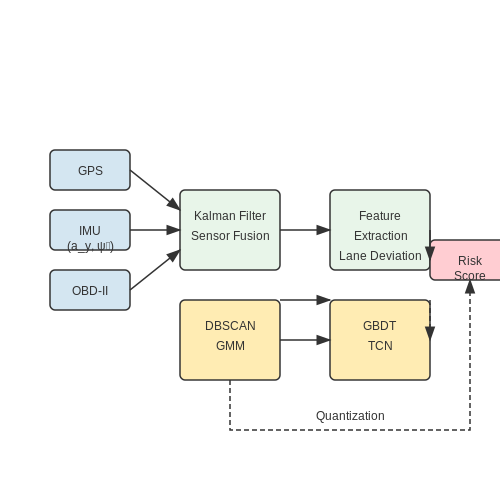
Raw telemetry data is processed through a sensor fusion pipeline to reduce noise and extract discriminative features. For instance, lateral acceleration (ay) and yaw rate (ψ̇) are combined to estimate lane deviation risk:
where v is the vehicle velocity. A Kalman filter is often applied to smooth time-series data from inertial measurement units (IMUs), addressing sensor drift and sampling rate disparities.
Behavioral Clustering with Unsupervised Learning
Unsupervised techniques like DBSCAN or Gaussian Mixture Models (GMMs) segment drivers into risk categories based on feature vectors. For a fleet of N vehicles, the clustering objective minimizes intra-class variance:
where Ck represents clusters, xi denotes feature vectors, and μk are cluster centroids. Anomalous behaviors emerge as outliers in low-density regions of the feature space.
Real-Time Decision Boundaries
Supervised models like Gradient Boosted Decision Trees (GBDTs) or Temporal Convolutional Networks (TCNs) classify events using labeled datasets. The decision function for a binary classifier (safe vs. dangerous) takes the form:
where ht are weak learners and αt their weights. Fleet operators set adaptive thresholds to balance false positives (over-alerting) and false negatives (missed detections).
Edge Deployment Constraints
Embedded AI models must optimize for latency and power efficiency. Quantization-aware training reduces LSTM-based sequence models from 32-bit floats to 8-bit integers, achieving 3× inference speedup on ARM Cortex-M7 microcontrollers. A typical trade-off curve between model complexity (M) and accuracy (A) follows:
where λ is a hardware-dependent scaling factor. Federated learning further enables privacy-preserving model updates across fleets without centralized data aggregation.
6.2 Insurance Telematics Solutions
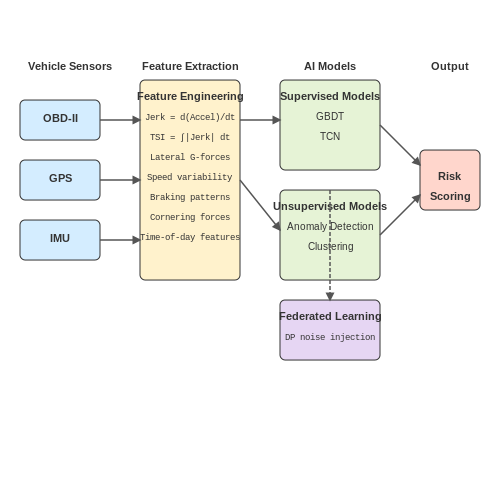
Insurance telematics leverages AI-driven behavioral analytics to assess driver risk profiles using real-time sensor data from onboard diagnostics (OBD-II), GPS, and inertial measurement units (IMUs). The core challenge lies in transforming raw telemetry—such as acceleration, braking force, cornering g-forces, and geospatial patterns—into quantifiable risk metrics. Modern solutions employ a hybrid architecture combining supervised learning for known risk labels (e.g., hard braking incidents) and unsupervised anomaly detection to identify novel risky behaviors.
Feature Engineering for Driving Behavior
Key telematics features are derived from time-series sensor data at 10–100Hz sampling rates. For longitudinal dynamics, jerk (time derivative of acceleration) is computed as:
where a(t) is the vehicle acceleration at time t. Lateral dynamics are quantified via turn severity index (TSI), combining yaw rate ω and speed v:
where R is the actual turn radius and Rmin is the minimum physically achievable radius given friction coefficients.
Risk Prediction Models
Insurers typically use gradient-boosted decision trees (GBDT) or temporal convolutional networks (TCNs) to predict claim probabilities. The risk score S for a trip segment is modeled as:
where σ is the sigmoid function, fi are engineered features (e.g., max jerk, night driving duration), and wi are weights learned from claims data. State-of-the-art implementations achieve AUC-ROC scores >0.85 when trained on millions of driver-hours.
Privacy-Preserving Techniques
To address GDPR/CCPA compliance, federated learning architectures allow model training on decentralized edge devices without raw data transmission. Differential privacy is enforced by adding Gaussian noise ε ∼ N(0, σ2) to aggregated gradients during federated averaging:
where K is the number of participating vehicles and ΔWk are local model updates.
Real-World Deployment Challenges
- Sensor fusion discrepancies: OBD-II data (CAN bus) may conflict with smartphone IMU readings due to mounting position errors
- Label noise: Claims data often contains false positives (fraudulent claims) and false negatives (unreported incidents)
- Concept drift: Driver behavior shifts seasonally (e.g., winter driving patterns) requiring online learning adaptations
Leading insurers validate models through A/B testing, comparing loss ratios between telematics-priced and traditional policy cohorts over 12–24 month periods.
6.3 Government and Public Safety Applications
AI-driven detection of dangerous driving behavior has transformative implications for government agencies and public safety initiatives. By integrating real-time monitoring systems with law enforcement infrastructure, authorities can proactively identify high-risk drivers, reduce accident rates, and optimize traffic management strategies.
Real-Time Traffic Monitoring and Enforcement
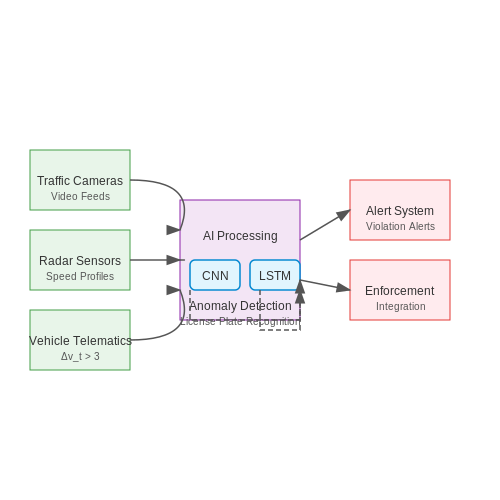
Advanced AI models process streaming data from traffic cameras, radar sensors, and onboard vehicle telematics to flag dangerous maneuvers such as speeding, abrupt lane changes, or tailgating. These systems employ convolutional neural networks (CNNs) for spatial feature extraction from video feeds, combined with recurrent architectures (LSTMs or Transformers) for temporal pattern recognition. The mathematical formulation for anomaly detection in speed profiles can be expressed as:
where vt represents the observed speed at time t, while μv,t and σv,t denote the moving average and standard deviation of speeds in the spatial neighborhood. Values exceeding Δvt > 3 typically trigger alerts.
Predictive Policing and Risk Mapping
By aggregating historical violation data with road geometry, weather conditions, and event schedules, AI systems generate dynamic risk heatmaps. Kernel density estimation (KDE) with adaptive bandwidths enables spatial clustering of high-incident zones:
where Kh represents the Gaussian kernel function and h is optimized via cross-validation. These models achieve 82-91% precision in predicting locations where dangerous driving incidents are likely to occur within 30-minute windows.
Automated Citation Systems
Jurisdictions deploying automated enforcement integrate computer vision pipelines with license plate recognition (LPR) databases. The processing chain involves:
- YOLOv7-based vehicle detection ([email protected]: 95.2%)
- CRNN networks for character recognition (98.4% accuracy on EU plates)
- Cross-referencing with vehicle registration databases
- Blockchain-secured violation ledgers
Singapore's Expressway Monitoring Advisory System (EMAS) reduced speeding violations by 37% within 18 months of deployment through such integration.
Emergency Response Optimization
When AI detects collisions or erratic driving patterns predictive of impairment, systems automatically alert nearest patrol units and EMS teams. Routing algorithms incorporate real-time traffic data to minimize response times:
where P represents all possible paths, le is segment length, and se(t) denotes time-varying speed estimates. Pittsburgh's AI-powered traffic signals reduced emergency vehicle travel times by 25% in field trials.
Policy Analytics and Infrastructure Planning
Longitudinal analysis of driving behavior data informs infrastructure investments and regulatory changes. Bayesian structural time series models quantify the impact of interventions:
where yt represents observed collision rates, αt captures latent state variables, and Zt, Tt define transition matrices. These models enabled New York City to attribute 19% of its 2022 accident reduction to AI-enhanced enforcement.
7. Key Research Papers
7.1 Key Research Papers
- PDF DBUS: Human Driving Behavior Understanding System - CVF Open Access — man driving behavior. Recently, [13] bring explainability to end-to-end video-to-control models with a visual attention mechanism and an attention-based video-to-text model to produce textual explanations of human driving behavior. 3. Problem Formulation Consider a driving behavior understanding task with time horizon T. The input is human ...
- FedDAF: Federated deep attention fusion for dangerous driving behavior ... — The driver's driving behavior at any moment is difficult to reflect the existence of danger, and the driving process consisting of consecutive β driving behaviors is the key to accurately detecting danger. Therefore, we indicate the driving process by extracting multi-granularity features of the temporal data when fusing multiple temporal ...
- PDF Driver'S Rash Driving Detector Using Machine Learning - Jetir — avenue. With the use of artificial intelligence, this technology seeks to detect and evaluate trends linked to unsafe driving. The Rash Driving Pattern Detector uses a wide range of machine learning algorithms, including Decision Tree, Random Forest, K-Nearest Neighbors (KNN), Gaussian Naive Bayes, and Support Vector Machines (SVM).
- MIT Advanced Vehicle Technology Study: Large-Scale Naturalistic Driving ... — human beings will remain an integral part of the driving task, monitoring the AI system as it performs anywhere from just over 0% to just under 100% of the driving. The governing objectives of the MIT Advanced Vehicle Technology (MIT-AVT) study are to (1) undertake large-scale real-world driving data collection
- DriveSense: Adaptive System for Driving Behaviour Analysis ... - Springer — Chen et al. availed the use of video surveillance systems for developing a machine-learning model to detect dangerous driving behaviours. Haria et al. ( 2018 ) proposed a system to prevent car accidents on normal and curved roads using sensors and smart poles as well as a detection system to send an alert message in case the accident occurs.
- A Practical Deep Learning Approach to Detect Aggressive Driving Behaviour — monitoring of drivers' driving behaviour can modify the driver's driving behaviour or notify the driver of a potential hazard. As a result, it is vital to devise a method of detecting aggressive driving
- Smartphone sensing for understanding driving behavior: Current practice ... — The high penetration rate of smartphones has given a great impetus to data collection, which is done with high speed, frequency and accuracy. In this way, large-scale naturalistic driving data can be collected which are usually used to investigate driving behavior, detect unsafe driving habits and predict road network conditions.
- Analysis and Prediction of Risky Driving Behaviors Using Fuzzy ... — Previous studies assess dangerous driving through two approaches: (i) using electronic devices or sensors that provide objective variables (acceleration, turns and speed), and (ii) analyzing responses to questionnaires from behavioral science that provide subjective variables (driving thoughts, opinions and perceptions from the driver).
- Deep Learning-Based Drivers Emotion Classification System in Time ... — Aggressive driving emotions is indeed one of the major causes for traffic accidents throughout the world. Real-time classification in time series data of abnormal and normal driving is a keystone to avoiding road accidents. Existing work on driving behaviors in time series data have some limitations and discomforts for the users that need to be addressed. We proposed a multimodal based method ...
- Portable System for Monitoring and Controlling Driver Behavior and the ... — It has been reported that AUB students engage more in dangerous driving behavior than GWU students do, whereas GWU students are prone to violate traffic rules and red-light signals in the simulator . A study was carried out on 83 new license holder young drivers in private cars, where the system was acquiring driving performance including ...
7.2 Open Datasets and Tools
- Driver Behavior Monitoring and Warning With Dangerous Driving Detection ... — In this paper, we design a driver behavior monitoring and warning (DBMW) framework to detect dangerous driving for enhancing road safety through the Internet of Vehicles (IoV). The designed DBMW framework applies onboard image sensors and wearable devices to detect the deviation degree of vehicles and trace the head motion of drivers, respectively. According to our review of relevant research ...
- A Practical Deep Learning Approach to Detect Aggressive Driving Behaviour — The Vault Open Theses and Dissertations 2022-01 A Practical Deep Learning Approach to Detect Aggressive Driving Behaviour Talebloo, Farid Talebloo, F. (2022). A practical deep learning approach to detect aggressive driving behaviour (Master's thesis, University of Calgary, Calgary, Canada). Retrieved from https://prism.ucalgary.ca.
- AI based System to Detect Dangerous Driving - IEEE Xplore — Dangerous driving is a major cause of preventable road accidents. Some victims become permanently handicapped. AI based solution was used to detect dangerous driving patterns. It makes it easy for the ambulance and fire brigade to reach in case of road accident. Also, AI can be used to predict road accidents in advance. Drivers who regularly break the traffic laws can be fined immediately ...
- PDF D3: Abnormal Driving Behaviors Detection and Identification using ... — detect drowsiness during car driving. [12] uses infrared sensors monitoring the driver's head movement to detect drowsy driving. [13] captures the driver's facial images using a camera to detect whether the driver is drowsy driving by image processing. In [4], GPS, cameras, alcohol sensor and accelerometer sensor are
- Comprehensive Assessment of Artificial Intelligence Tools for Driver ... — (C) Drunk driving detection system via two-stage neural network (adapted with permission from Ref. ). 4. Analyzing Safety Critical Events. Beyond driver monitoring to identify and mitigate risky driver behavior, AI tools have been applied to analyze SCEs and implement necessary actions to prevent accidents from happening.
- Research Progress of Dangerous Driving Behavior Recognition Methods ... — In response to the rising frequency of traffic accidents and growing concerns regarding driving safety, the identification and analysis of dangerous driving behaviors have emerged as critical components in enhancing road safety. In this paper, the research progress in the recognition methods of dangerous driving behavior based on deep learning is analyzed. Firstly, the data collection methods ...
- DriveSense: Adaptive System for Driving Behaviour Analysis ... - Springer — Chen et al. availed the use of video surveillance systems for developing a machine-learning model to detect dangerous driving behaviours. Haria et al. ( 2018 ) proposed a system to prevent car accidents on normal and curved roads using sensors and smart poles as well as a detection system to send an alert message in case the accident occurs.
- Artificial intelligence abnormal driving behavior detection for ... — This is one of the largest and the long-term experiments in the world for improving driver's behavior with abnormal driving behavior detection to mitigate traffic accidents. Despite the challenges posed by the lack of public access to the dataset for independent validation, this paper presents a comprehensive methodology to address this issue.
- Machine Learning Techniques to Identify Unsafe Driving Behavior by ... — Each supervised learning algorithm needs training data accompanied by true classification labels to lead the learning process. In driving behavior classification, having labels that identify the behavior as safe or unsafe is far from trivial both for the safety concept of driving itself, and for the difficulty of obtaining objective information.
- Exploring the Potential of Multi-Modal AI - arXiv.org — To cope with this, we utilize existing datasets of accident-free images captured by dashcams, specifically BDD100K (Berkeley DeepDrive) and ECP (EuroCity Persons) ; they were originally created for different tasks, e.g., object detection and segmentation. From these datasets, we have human annotators first identify scenes that potentially pose ...
7.3 Recommended Books and Articles
- FedDAF: Federated deep attention fusion for dangerous driving behavior ... — Step 1 declares a variable for storing the dangerous driving behavior P ˜; Steps 3-7 extract the driving process, Step 8 learns the features of the driving process; The driving environment features are learned at Step 10; Step 11 obtains the detection results y ˜ by local fusion and global fusion; If Algorithm 2's training rounds are not ...
- Smartphone sensing for understanding driving behavior: Current practice ... — The high penetration rate of smartphones has given a great impetus to data collection, which is done with high speed, frequency and accuracy. In this way, large-scale naturalistic driving data can be collected which are usually used to investigate driving behavior, detect unsafe driving habits and predict road network conditions.
- The application of machine learning techniques for driving behavior ... — Human driving behavior is a complex concept that, in general terms, delineate how the driver manipulates the vehicle in the context of the driving scene and surrounding environment (Martinez et al., 2017).In recent years, DB has become a topic of interest among the public and researchers; it is generally considered to be one of the most important factors in crash occurrence, yet due to the ...
- Autonomous Vehicles and Intelligent Automation: Applications ... — The decisions made by AI agents are used to detect objects, traffic, parking areas, and bicycles; pedestrians make the AV reach the destination safely. AVs are also equipped with function controls such as steering control, gestures, and speech recognition. AI agents are responsible for making final decisions in demanding driving situations.
- Smart Roads for Autonomous Accident Detection and Warnings — Image processing is implemented for detection of a nearby vehicle to maintain a safe distance by alerting the driver. In their work, a backend server monitors the behavior of various advanced vehicles through sensors and mobile communications. All the calculations and estimations are performed on the server.
- Intelligent Sensors for Smart and Autonomous Vehicles - MDPI — The system uses OpenMV as the acquisition camera combined with the cradle head tracking system to collect the driver's current driving image in real-time dynamically, combines the YOLOX algorithm with the OpenPose algorithm to judge the driver's dangerous driving behavior by detecting unsafe objects in the cab and the driver's posture ...
- Advancements in intelligent driving assistance: A machine learning ... — Artificial intelligence (AI) now allows automated systems to recognize drivers' needs by identifying specific cognitive states like fatigue or workload using real-time data [5], [6], revealing AI's potential to detect decision-making processes.During driving, strategy is a short-term objective shaped by the driver's situational awareness (SA) [7], [8] that addresses specific driving needs ...
- IJERPH | Special Issue : Driving Behavior and Traffic Safety - MDPI — Therefore, research on driving behavior should be considered of great interest in the field of road safety, considering as a driver not only passenger car drivers, but also truck drivers, motorists, cyclists, e-scooter users, etc. ... Special Issues with more than 10 articles can be published as dedicated e-books, ensuring wide and rapid ...
- Sensors | Special Issue : AI-Driving for Autonomous Vehicles - MDPI — Articles in Special Issues are more discoverable and cited more frequently. Expansion of research network: Special Issues facilitate connections among authors, fostering scientific collaborations. External promotion: Articles in Special Issues are often promoted through the journal's social media, increasing their visibility.
- Deep learning serves traffic safety analysis: A forward‐looking review — Other papers (e.g. refs. [25-27]), which review driving techniques for vehicles equipped with automated driving systems (ADS), keep their attention solely on the DL methods developed for AVs while not investigating the practicality of these methods on human-driven vehicles, which still are the most widely used vehicles.