Multi-Objective Optimization in AI
1. Key Concepts and Definitions
1.1 Key Concepts and Definitions
Multi-objective optimization (MOO) addresses problems where multiple, often conflicting, objectives must be optimized simultaneously. Unlike single-objective optimization, MOO does not yield a single optimal solution but a set of Pareto-optimal solutions, where no objective can be improved without degrading another. Formally, a MOO problem is defined as:
where 𝒳 is the feasible decision space, 𝐱 is the decision vector, and 𝐅(𝐱) is the vector of k objective functions. The Pareto dominance relation is central to MOO: a solution 𝐱(1) dominates 𝐱(2) (denoted 𝐱(1) ≺ 𝐱(2)) if:
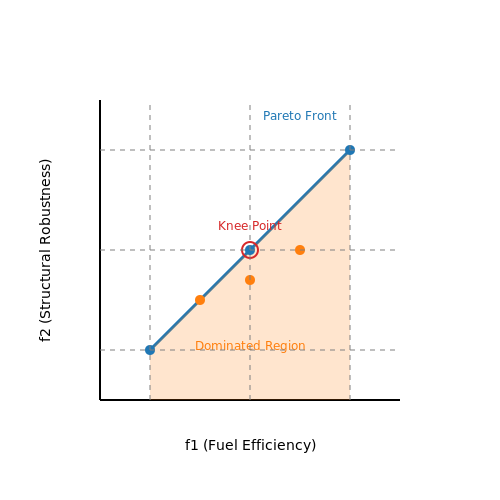
The Pareto front is the set of non-dominated solutions in the objective space, representing optimal trade-offs. For example, in aerospace design, objectives like fuel efficiency (f1) and structural robustness (f2) often conflict; the Pareto front quantifies achievable compromises.
Critical MOO Terminology
- Hypervolume: A metric evaluating the volume dominated by a Pareto front relative to a reference point. Larger values indicate better convergence and diversity.
- Knee Points: Solutions on the Pareto front where a small improvement in one objective requires large sacrifices in others.
- Scalarization: Techniques like weighted sums or Chebyshev methods that convert MOO into single-objective problems.
Evolutionary Approaches
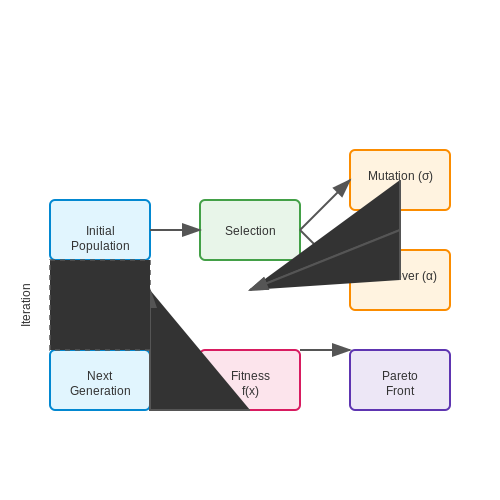
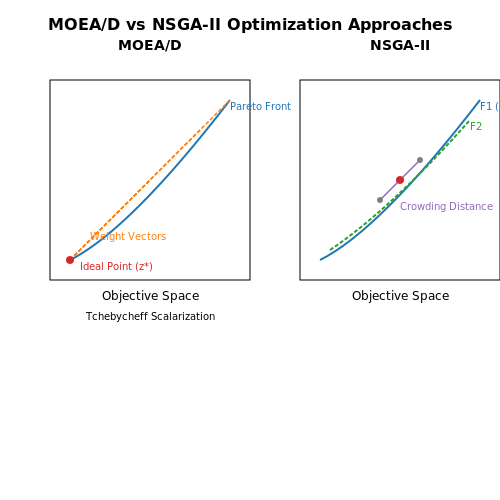
Algorithms like NSGA-II (Non-dominated Sorting Genetic Algorithm) and MOEA/D (Multi-Objective Evolutionary Algorithm based on Decomposition) exploit population-based search to approximate Pareto fronts. NSGA-II uses non-dominated sorting and crowding distance to preserve diversity, while MOEA/D decomposes the problem into scalar subproblems.
where 𝐰 is a weight vector and 𝐳* is the ideal objective vector. These methods are widely applied in logistics, robotics, and financial portfolio optimization.
Pareto Optimality and Dominance
In multi-objective optimization, Pareto optimality defines a solution where no objective can be improved without degrading at least one other objective. Formally, a solution x* is Pareto optimal if there does not exist another solution x such that:
and
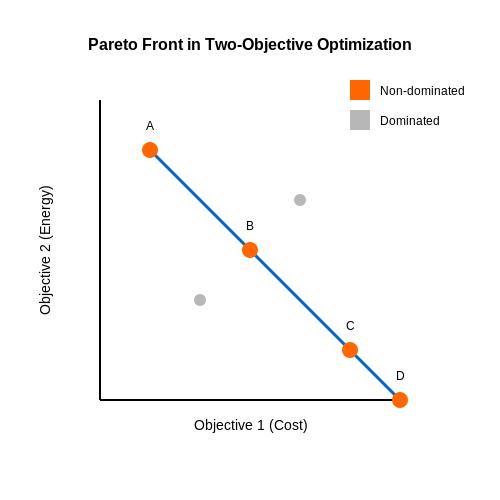
where k is the number of objectives. The set of all Pareto optimal solutions forms the Pareto front, representing the trade-offs between conflicting objectives.
Dominance Relations
A solution x1 dominates another solution x2 (denoted as x1 ≺ x2) if:
and
If neither solution dominates the other, they are non-dominated. This relation is fundamental in evolutionary algorithms like NSGA-II, where non-dominated sorting is used to rank solutions.
Visualizing the Pareto Front
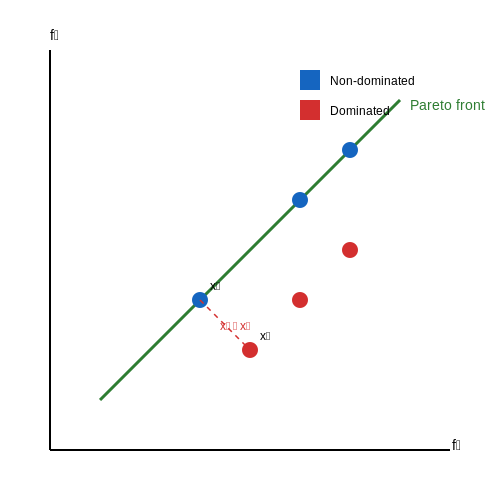
The Pareto front in a two-objective minimization problem can be visualized as a curve where each point represents a non-dominated solution. For example, in a problem minimizing both cost and energy consumption, the Pareto front shows the best possible trade-offs between these objectives.
Practical Applications
Pareto optimality is widely used in engineering design, economics, and machine learning hyperparameter tuning. For instance, in neural architecture search, the trade-off between model accuracy and computational complexity can be analyzed using Pareto dominance to identify optimal architectures.
Extensions and Variants
Several extensions of Pareto dominance exist to handle specific scenarios:
- Weak Dominance: A solution x1 weakly dominates x2 if it is not worse in any objective, but not necessarily better in at least one.
- ε-Dominance: Introduces a tolerance threshold ε to relax the dominance condition, useful in noisy or approximate optimization.
- Preference-Based Dominance: Incorporates user preferences to prioritize certain objectives over others.
Trade-offs and Objective Space
In multi-objective optimization, the concept of trade-offs arises when improving one objective necessitates degrading another. The objective space provides a geometric representation of these trade-offs, where each point corresponds to a solution's performance across all objectives. For k objectives, the objective space is a k-dimensional space, with each axis representing an objective function value.
Pareto Optimality and Dominance
A solution is Pareto optimal if no other solution exists that improves at least one objective without worsening another. Mathematically, a solution x* is Pareto optimal if:
The set of all Pareto optimal solutions forms the Pareto front, which represents the best possible trade-offs in the objective space. Visualizing the Pareto front in 2D or 3D helps decision-makers understand the compromises between objectives.
Visualizing the Objective Space
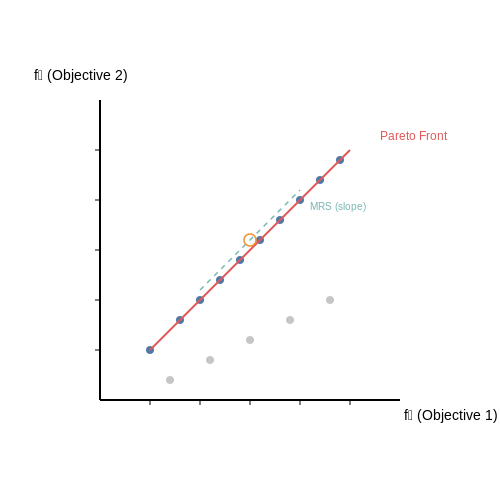
Consider a bi-objective minimization problem where f₁(x) and f₂(x) represent conflicting objectives (e.g., cost vs. performance). The objective space plots f₁(x) on the x-axis and f₂(x) on the y-axis. The Pareto front appears as a curve where moving left (improving f₁) requires moving up (worsening f₂), and vice versa.
Trade-off Analysis
Quantifying trade-offs involves calculating the marginal rate of substitution (MRS) between objectives. For two objectives, the MRS at a point on the Pareto front is the slope of the tangent line at that point:
This value indicates how much of f₂ must be sacrificed to gain a unit improvement in f₁. A steep slope implies a high cost for improving f₁, while a shallow slope suggests a favorable trade-off.
Practical Implications
In engineering design, trade-offs often involve:
- Performance vs. Cost: Higher accuracy models may require more computational resources.
- Robustness vs. Complexity: Simpler models may generalize better but lack precision.
- Energy Efficiency vs. Speed in hardware design.
Multi-objective optimization algorithms (e.g., NSGA-II, MOEA/D) explicitly explore the objective space to approximate the Pareto front, enabling decision-makers to select solutions aligned with their priorities.
2. Evolutionary Algorithms (MOEA/D, NSGA-II)
Evolutionary Algorithms (MOEA/D, NSGA-II)
Multi-Objective Evolutionary Algorithms (MOEAs)
Multi-Objective Evolutionary Algorithms (MOEAs) are population-based optimization techniques inspired by natural selection. Unlike single-objective optimization, MOEAs handle multiple conflicting objectives simultaneously, producing a set of Pareto-optimal solutions. Two prominent algorithms in this domain are MOEA/D (Multi-Objective Evolutionary Algorithm Based on Decomposition) and NSGA-II (Non-Dominated Sorting Genetic Algorithm II).
MOEA/D: Decomposition-Based Approach
MOEA/D decomposes a multi-objective problem into several single-objective subproblems using aggregation functions, typically weighted sums or Tchebycheff approaches. Given m objectives, the Tchebycheff scalarization function for a subproblem with weight vector λ is:
where z* is the ideal reference point. MOEA/D optimizes these subproblems in parallel, leveraging neighborhood information to share solutions among similar subproblems. This approach ensures diversity while maintaining convergence.
NSGA-II: Non-Dominated Sorting and Crowding Distance
NSGA-II employs a two-stage ranking mechanism:
- Non-dominated sorting: Solutions are sorted into Pareto fronts (F1, F2, ...) based on dominance relationships.
- Crowding distance: Within each front, solutions are ranked by their spread in objective space to preserve diversity.
The selection process combines these metrics to prioritize non-dominated solutions with higher crowding distances. The algorithm’s computational complexity is O(MN²), where M is the number of objectives and N is the population size.
Key Differences and Practical Considerations
While both algorithms aim for Pareto-optimality, their mechanisms differ:
- MOEA/D is suited for problems where decomposition aligns with the Pareto front geometry.
- NSGA-II excels in maintaining diversity but may struggle with many-objective problems (M > 3).
Hybrid approaches, such as combining decomposition with crowding distance, have been proposed to address limitations in scalability and convergence.
Applications and Case Studies
MOEAs are widely applied in engineering design, finance, and logistics. For example:
- Aerospace: Optimizing aircraft wing design for minimal weight and maximal lift.
- Energy systems: Balancing cost and emissions in power grid scheduling.
2.2 Gradient-Based Methods
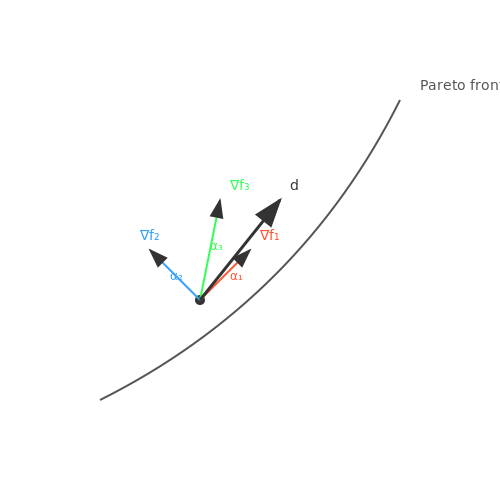
Gradient-based methods are a cornerstone of multi-objective optimization, leveraging the differentiability of objective functions to navigate the Pareto front efficiently. These methods extend single-objective gradient descent by incorporating mechanisms to balance conflicting objectives. The core idea revolves around computing a combined gradient direction that optimizes all objectives simultaneously without favoring any single one disproportionately.
Mathematical Formulation
Consider a multi-objective optimization problem with k objectives:
where fi(x) are differentiable functions. The gradient of each objective ∇fi(x) provides the direction of steepest ascent. To descend toward the Pareto front, we seek a direction d that minimizes all objectives simultaneously. This is achieved by solving:
This minimax problem ensures no single objective's gradient dominates the search direction. The solution yields a descent direction that balances all objectives, often computed via quadratic programming or Frank-Wolfe methods.
Multiple Gradient Descent Algorithm (MGDA)
MGDA is a prominent gradient-based method that generalizes gradient descent to multi-objective settings. At each iteration, it computes a convex combination of individual gradients:
The coefficients αi are determined by solving a quadratic program to minimize ||d||2, ensuring the direction is Pareto-stationary. If the gradients are linearly independent, MGDA converges to a point on the Pareto front where no objective can be improved without degrading another.
Practical Considerations
Gradient-based methods require differentiable objectives and are sensitive to scaling disparities between objectives. Normalization or adaptive weighting schemes are often employed to mitigate bias toward objectives with larger gradients. Additionally, stochastic variants exist for large-scale problems, where gradients are approximated via mini-batch sampling.
In neural architecture search, for instance, MGDA has been applied to balance accuracy and computational efficiency. By treating each objective's gradient as a separate loss, the optimizer discovers architectures that trade off performance and resource constraints effectively.
Extensions and Variants
Recent advancements include:
- Adaptive MGDA: Dynamically adjusts αi based on gradient magnitudes to handle non-uniform sensitivities.
- Projected Gradient Methods: Incorporate constraints by projecting gradients onto feasible sets, useful in robotics trajectory optimization.
- Hessian-Aware Methods: Leverage second-order information to account for curvature, improving convergence in ill-conditioned landscapes.
2.3 Decomposition Techniques
Decomposition techniques in multi-objective optimization (MOO) transform a complex problem into simpler subproblems, often by scalarizing the objectives or partitioning the search space. These methods are particularly effective in evolutionary algorithms, where they enable parallel exploration of diverse regions of the Pareto front.
Weighted Sum Approach
The weighted sum method scalarizes multiple objectives into a single objective function by assigning weights to each component. Given m objectives f1(x), f2(x), ..., fm(x), the aggregated function is:
where wi are non-negative weights such that ∑wi = 1. While computationally efficient, this method struggles with non-convex Pareto fronts due to its inability to discover solutions in concave regions.
Tchebycheff Decomposition
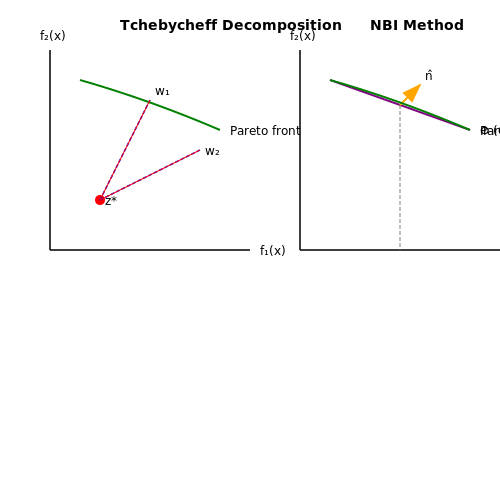
Tchebycheff decomposition addresses the limitations of the weighted sum method by minimizing the maximum weighted deviation from a reference point z* (e.g., the ideal objective vector). The scalarized problem becomes:
This approach guarantees finding all Pareto optimal solutions for convex and non-convex fronts, provided the weights are appropriately varied. However, it introduces non-differentiability, complicating gradient-based optimization.
Boundary Intersection (BI) Methods
BI methods, such as Normal Boundary Intersection (NBI), explicitly construct evenly distributed points along the Pareto front. The NBI approach:
- Computes the convex hull of individual minima (CHIM) to define a hyperplane in objective space.
- Generates evenly distributed weight vectors w on this hyperplane.
- Solves subproblems that minimize distance to the hyperplane along predefined directions.
where Φ is the CHIM matrix and n̂ is the normal vector to the hyperplane. NBI performs well for continuous fronts but may fail with disconnected or highly irregular Pareto sets.
Dynamic Decomposition in MOEA/D
The Multi-Objective Evolutionary Algorithm based on Decomposition (MOEA/D) dynamically manages subproblems during optimization. Each subproblem i is defined by:
or alternatively using Tchebycheff or penalty-based boundary intersection (PBI) scalarizations. Neighborhood relations between weight vectors allow information sharing, balancing exploration and exploitation. MOEA/D's efficiency stems from:
- Parallel subproblem optimization: Multiple solutions evolve simultaneously.
- Adaptive resource allocation: Computational effort focuses on promising regions.
- Diversity preservation: Weight vector spacing maintains solution spread.
Recent variants incorporate adaptive weight adjustment and surrogate models to handle computationally expensive objectives.
Kernel-Based Decomposition
Kernel methods project objectives into a high-dimensional feature space where linear decomposition becomes more effective. The scalarized objective in the reproducing kernel Hilbert space (RKHS) is:
where φ is the feature map and μ is a reference vector. This approach excels in problems with nonlinear objective correlations but incurs higher computational costs due to kernel matrix operations.
3. Hyperparameter Tuning
3.1 Hyperparameter Tuning
Hyperparameter tuning is a critical step in optimizing machine learning models, particularly in multi-objective scenarios where competing objectives must be balanced. Unlike model parameters learned during training, hyperparameters are set prior to training and govern the learning process itself. Examples include learning rates, regularization coefficients, and architectural choices like layer sizes in neural networks.
Mathematical Formulation
Given a model f with hyperparameters λ and training data D, the optimization problem can be framed as:
where Λ is the hyperparameter space and ℒ represents a loss function. In multi-objective optimization, this extends to:
where k competing objectives must be minimized simultaneously.
Pareto Optimality in Hyperparameter Tuning
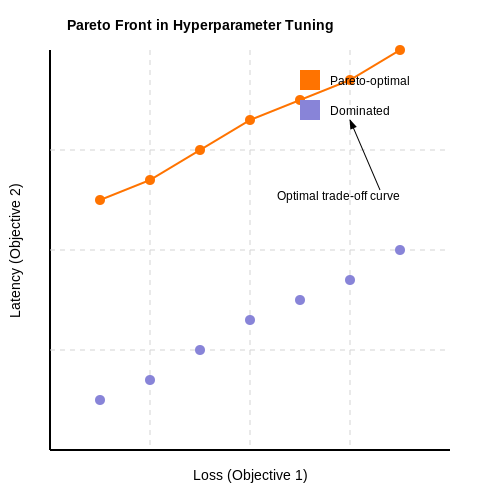
A hyperparameter configuration λ* is Pareto optimal if no other configuration dominates it across all objectives. Formally, λ* is Pareto optimal if there does not exist any λ' such that:
Common Optimization Strategies
Grid Search and Random Search
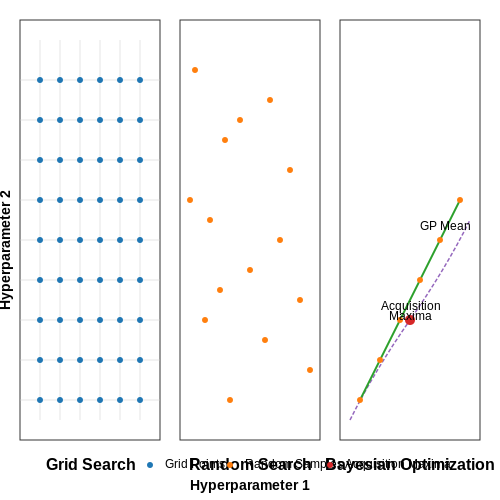
Grid search exhaustively evaluates predefined hyperparameter combinations, while random search samples configurations stochastically. Random search often outperforms grid search in high-dimensional spaces due to better coverage probability.
Bayesian Optimization
Bayesian optimization constructs a probabilistic model of the objective function and uses it to select promising hyperparameters. The acquisition function balances exploration and exploitation:
where α is the acquisition function and 𝒟1:t contains previous evaluations.
Multi-Objective Evolutionary Algorithms
Algorithms like NSGA-II (Non-dominated Sorting Genetic Algorithm) maintain a population of solutions and evolve them using genetic operators. The key steps are:
- Non-dominated sorting to rank solutions
- Crowding distance computation to preserve diversity
- Selection, crossover, and mutation to generate offspring
Practical Considerations
When implementing multi-objective hyperparameter tuning:
- Scalability: The computational cost grows exponentially with the number of objectives and hyperparameters.
- Objective Normalization: Objectives may operate on different scales, requiring normalization or weighting.
- Early Stopping: Techniques like Hyperband can terminate poorly performing configurations early to save resources.
Case Study: Neural Architecture Search
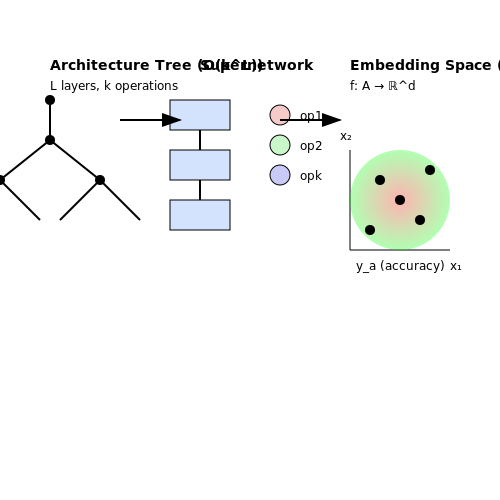
In neural architecture search (NAS), hyperparameters define the network structure. A multi-objective approach might optimize both accuracy and latency:
Recent work uses gradient-based methods to optimize architecture parameters continuously, avoiding expensive discrete search.
Neural Architecture Search
Neural Architecture Search (NAS) automates the design of artificial neural networks, optimizing architectures for performance, computational efficiency, and other objectives. Unlike manual design, NAS employs search algorithms to explore a vast space of possible architectures, balancing trade-offs between accuracy, latency, and memory usage.
Search Spaces in NAS
The search space defines the set of possible architectures considered during optimization. Common approaches include:
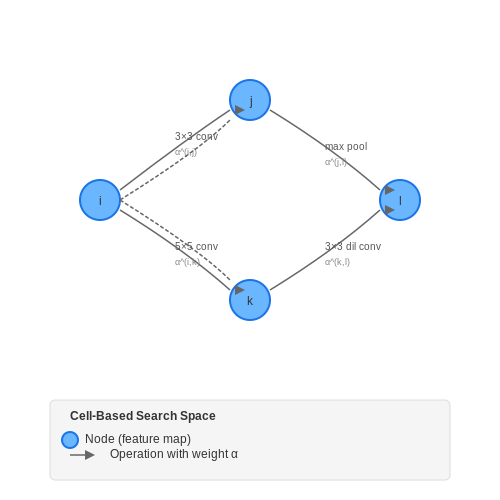
- Cell-based search spaces: Optimize repeating computational blocks (e.g., convolutional cells in CNNs).
- Hierarchical search spaces: Combine macro-architecture decisions (e.g., layer depth) with micro-architecture choices (e.g., kernel size).
- Continuous relaxation: Represent discrete architecture choices as differentiable parameters, enabling gradient-based optimization.
Optimization Strategies
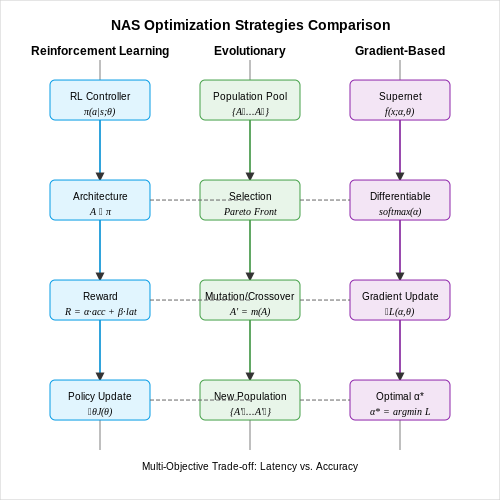
NAS methods typically employ one of three optimization paradigms:
where α denotes the architecture, wα its weights, ℒ the loss function, and 𝒞 a constraint (e.g., FLOPs).
1. Reinforcement Learning (RL)
RL-based NAS treats architecture generation as a sequential decision process. A controller (typically an RNN) proposes architectures, receives rewards based on validation performance, and updates its policy via policy gradients:
2. Evolutionary Algorithms
Evolutionary NAS maintains a population of architectures, applying mutation and crossover operations. Selection pressure favors architectures with higher fitness (e.g., validation accuracy). Pareto-optimization extensions handle multiple objectives:
3. Gradient-Based Optimization
Differentiable NAS (DNAS) relaxes the search space to be continuous, enabling efficient gradient descent. The architecture distribution is parameterized via softmax over candidate operations:
Multi-Objective NAS
Real-world applications often require optimizing multiple competing objectives. A common formulation combines accuracy and latency:
where λ controls the trade-off. Advanced methods employ:
- Pareto-frontier estimation to identify non-dominated architectures.
- Hypernetwork predictors to estimate architecture performance without full training.
- Resource-aware search with hardware-in-the-loop profiling.
Practical Considerations
State-of-the-art NAS frameworks (e.g., DARTS, ENAS, ProxylessNAS) address key challenges:
- Weight sharing: Enables efficient evaluation of candidate architectures via a supernet.
- Early stopping: Prunes poorly performing architectures using low-fidelity evaluations.
- Hardware-aware metrics: Incorporates device-specific latency/energy models into the search.
Recent advances like Once-for-All networks decouple training from search, enabling adaptive architectures for diverse deployment scenarios without retraining.
Fairness-Aware Model Training
Defining Fairness in Machine Learning
Fairness in machine learning requires that models do not exhibit discriminatory behavior toward protected groups defined by sensitive attributes such as race, gender, or age. Formally, fairness can be quantified using statistical parity, equalized odds, or predictive rate parity. For a binary classifier f(X) and sensitive attribute A, statistical parity demands:
Equalized odds extends this by conditioning on the true label Y, requiring equal true positive and false positive rates across groups:
Fairness-Aware Optimization Techniques
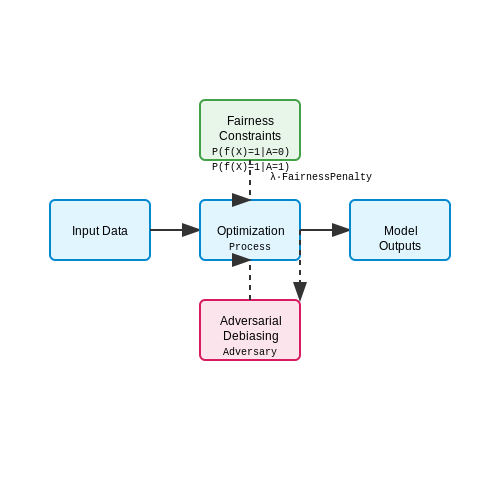
Fairness constraints can be integrated into model training via multi-objective optimization. The Lagrangian framework is commonly used to balance accuracy and fairness:
where λ controls the trade-off. Popular penalty terms include:
- Demographic parity penalty: ∥P(f(X)=1|A=0) − P(f(X)=1|A=1)∥
- Equalized odds penalty: ∑_(y∈{0,1}) ∥P(f(X)=1|A=0,Y=y) − P(f(X)=1|A=1,Y=y)∥
Adversarial Debiasing
Adversarial methods train a primary predictor alongside an adversary that attempts to predict the sensitive attribute from the model's outputs. The predictor learns to encode information useful for the main task while preventing the adversary from inferring A. The minimax objective is:
where φ parameterizes the adversary. This approach has been shown to satisfy fairness constraints while maintaining predictive performance.
Pre-processing vs. In-processing
Fairness interventions can occur at different stages:
- Pre-processing: Modify training data to remove biases (e.g., reweighting samples, transforming features).
- In-processing: Directly optimize fairness during model training (e.g., adversarial debiasing, constrained optimization).
- Post-processing: Adjust model outputs post-training (e.g., threshold tuning per group).
In-processing methods often provide better fairness-accuracy trade-offs but require modifying the training procedure. The choice depends on regulatory requirements, computational constraints, and whether the training data can be modified.
Case Study: Credit Scoring
In credit approval systems, fairness-aware training ensures loans are not disproportionately denied to protected groups. A 2021 study achieved 92% accuracy while reducing demographic parity difference from 15% to 3% using adversarial debiasing. The model used 20 demographic features and 100 financial indicators, with λ=0.8 providing optimal trade-off.
4. Scalability and Computational Cost
4.1 Scalability and Computational Cost
Scalability remains a critical challenge in multi-objective optimization (MOO), particularly as the number of objectives, decision variables, and constraints grows. The computational complexity of MOO algorithms often scales exponentially with problem dimensionality, making efficient optimization techniques essential for real-world applications.
Computational Complexity of MOO Algorithms
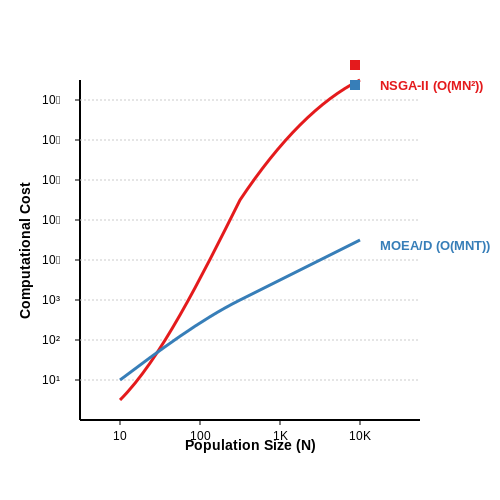
The computational cost of MOO algorithms is typically analyzed using Big-O notation. For example, the complexity of a basic Pareto-based algorithm like NSGA-II can be expressed as:
where M is the number of objectives and N is the population size. This quadratic scaling becomes prohibitive for large N, motivating the development of more efficient alternatives.
Challenges in High-Dimensional Spaces
As the number of objectives increases beyond 3-5, several fundamental challenges emerge:
- Pareto front complexity: The Pareto optimal surface becomes increasingly complex and difficult to approximate
- Selection pressure: The proportion of non-dominated solutions grows rapidly, reducing selection pressure
- Visualization difficulty: Human interpretation of high-dimensional trade-off surfaces becomes impractical
Scalability Enhancement Techniques
Several approaches have been developed to address scalability challenges:
Objective Reduction Methods
Techniques like principal component analysis (PCA) or nonlinear dimensionality reduction can identify redundant objectives. The objective reduction problem can be formulated as:
where X is the matrix of objective values and W is the projection matrix.
Decomposition-Based Approaches
MOEA/D decomposes the multi-objective problem into multiple single-objective subproblems using weight vectors. The computational complexity is:
where T is the neighborhood size, typically offering better scalability than Pareto-based methods.
Parallelization Strategies
Modern implementations leverage parallel computing to handle large-scale problems:
- Island models: Independent populations evolve in parallel with periodic migration
- Master-worker architectures: Fitness evaluations are distributed across workers
- GPU acceleration: Massively parallel evaluation of population members
Surrogate-Assisted Optimization
For expensive objective functions, surrogate models approximate the true objectives to reduce computational cost. A Gaussian process surrogate model predicts objectives as:
where m(x) is the mean function and k(x,x') is the covariance kernel.
4.2 Handling Conflicting Objectives
In multi-objective optimization, objectives often compete, meaning improving one may degrade another. This trade-off necessitates specialized techniques to navigate the Pareto front, the set of optimal solutions where no objective can be improved without sacrificing another. The challenge lies in balancing these conflicts while maintaining computational efficiency.
Pareto Optimality and Dominance
A solution x1 dominates another x2 (denoted x1 ≺ x2) if:
where k is the number of objectives. The Pareto front comprises all non-dominated solutions, forming the basis for decision-making in multi-objective problems.
Scalarization Methods
Scalarization transforms multiple objectives into a single objective, enabling traditional optimization techniques. Common approaches include:
- Weighted Sum: Combines objectives linearly with user-defined weights wi:
$$ F(x) = \sum_{i=1}^k w_i f_i(x), \quad w_i \geq 0, \sum w_i = 1 $$Limited to convex Pareto fronts due to its inability to capture concave regions.
- ε-Constraint: Optimizes one objective while constraining others below thresholds εi:
$$ \min f_j(x) \quad \text{subject to} \quad f_i(x) \leq \epsilon_i \ \forall i \neq j $$Effective but requires careful tuning of constraints.
Evolutionary Multi-Objective Optimization (EMO)
Algorithms like NSGA-II and MOEA/D evolve populations toward the Pareto front using dominance-based or decomposition-based strategies. Key mechanisms include:
- Crowding Distance: Preserves diversity by favoring solutions in sparsely populated regions of the objective space.
- Reference Points: Guides search toward user-preferred regions in MOEA/D by decomposing the problem into subproblems.
Preference Incorporation
Decision-maker preferences can be integrated a priori (e.g., weighting schemes), interactively (e.g., reference point updates), or a posteriori (Pareto front analysis). The Chebyshev method minimizes the maximum weighted deviation from ideal values:
where zi* is the ideal value for objective i.
Real-World Applications
Conflicting objectives arise in:
- Aerospace Design: Minimizing weight while maximizing structural integrity.
- Finance: Balancing risk and return in portfolio optimization.
- Energy Systems: Optimizing cost versus emissions in power grid dispatch.
4.3 Visualization of High-Dimensional Pareto Fronts
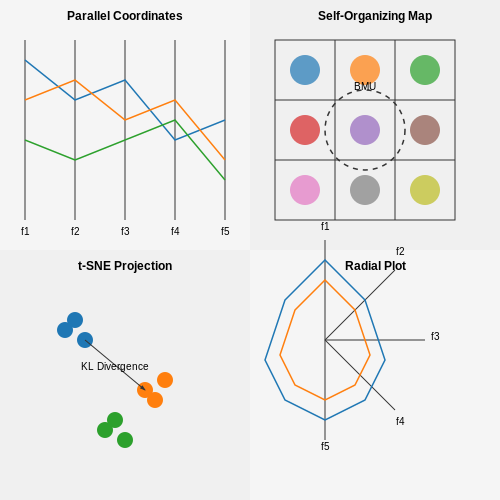
Visualizing Pareto fronts in high-dimensional objective spaces presents unique challenges due to the curse of dimensionality. Traditional 2D and 3D scatter plots become ineffective when the number of objectives exceeds three, necessitating specialized dimensionality reduction and projection techniques.
Parallel Coordinates
Parallel coordinates provide a scalable way to represent high-dimensional trade-offs. Each axis corresponds to an objective, and solutions are plotted as polylines intersecting each axis at their respective objective values. Dominance relationships can be inferred by comparing line crossings—non-dominated solutions tend to exhibit fewer crossings.
Self-Organizing Maps (SOMs)
SOMs project high-dimensional Pareto fronts onto a 2D grid while preserving topological relationships. The algorithm:
- Initializes a grid of neurons with random weight vectors
- For each solution, finds the best matching unit (BMU)
- Updates BMU and neighboring weights toward the solution
t-Distributed Stochastic Neighbor Embedding (t-SNE)
t-SNE minimizes the Kullback-Leibler divergence between high-dimensional and low-dimensional probability distributions:
Radial Visualization
Radial plots arrange objectives equidistantly on a circle, with solutions represented as closed shapes. The area of each shape corresponds to solution quality, enabling quick identification of balanced trade-offs.
Normalization Considerations
All visualization methods require proper objective scaling:
Interactive Exploration
Modern toolkits like Plotly and D3.js enable dynamic filtering and brushing of high-dimensional fronts. Key features include:
- Objective-space selection to highlight corresponding solutions
- Pareto rank filtering
- Parallel coordinate axis reordering
5. Key Research Papers
5.1 Key Research Papers
- PDF Multi-Objective Optimization using Evolutionary Algorithms — 1.4 Rise of Multi-Objective Evolutionary Algorithms 8 1.5 Organization of the Book 9 2 Multi-Objective Optimization 13 2.1 Multi-Objective Optimization Problem 13 2.1.1 Linear and Nonlinear MOOP 14 2.1.2 Convex and Nonconvex MOOP 15 2.2 Principles of Multi-Objective Optimization 16 2.2.1 Illustrating Pareto-Optimal Solutions 18
- A survey of recommender systems with multi-objective optimization — Traditional recommendation models usually deal with a single objective, such as minimizing the prediction errors [10] or maximizing the ranking quality [11].Recently, there is an emerging demand in multi-objective recommendations [12], where the recommendation models can be built by considering multiple objectives through a process of multi-objective optimization (MOO).
- A Comprehensive Review on Multi-objective Optimization ... - Springer — Realistic problems typically have many conflicting objectives. Therefore, it is instinctive to look at the engineering problems as multi-objective optimization problems. This paper briefly explains the multi-objective optimization algorithms and their variants with pros and cons. Representative algorithms in each category are discussed in depth. Applications of various multi-objective ...
- Efficient Multi-Objective Optimization for Deep Learning - arXiv.org — for multi-objective optimization is the Multiple-Gradient-Descent-Algorithm (MGDA) (Desid´ ´eri ,2012). Actually, one of the first papers to treat multi-task learning as multi-objective optimization used the MGDA method for training a single Pareto stationary solution (Sener & Koltun,2018). Follow-up techniques extended the idea towards learning
- A tutorial on multiobjective optimization: fundamentals and ... — Remark 1. In general, we would demand m > 1 when we talk about multiobjective optimization problems. Moreover, there is the convention to call problems with large m, not multiobjective optimization problems but many-objective optimization problems (see Fleming et al. 2005; Li et al. 2015).The latter problems form a special, albeit important case of multiobjective optimization problems.
- Multimodal multi-objective optimization: A preliminary study — In real world applications, there are many multi-objective optimization problems. Most existing multi-objective optimization algorithms focus on improving the diversity, spread and convergence of the solutions in the objective space. Few works study the distribution of solutions in the decision space. In practical applications, some multi-objective problems have different Pareto sets with the ...
- Interactive multi-objective evolutionary optimization of software ... — This paper presents an interactive multi-objective evolutionary algorithm aimed at supporting software engineers during the early analysis process. The combination of multi-objective optimization techniques with the so-called architectural preferences guides the search towards the joint optimization of both objective and subjective criteria.
- PDF Jin Song Dong Multi-Objective Optimization using Artificial ... — The algorithms are Multi-objective Particle Swarm Optimizer (MOPSO), Multi-Objective Genetic Algorithm (NSGA-II), and Multi-objective Grey Wolf Optimizer (MOGWO). Brisbane, Australia Dr. Seyedali Mirjalili July 2019 Prof. Jin Song Dong vii
- A Systematic Review of Multi-Objective Evolutionary Algorithms ... - MDPI — This paper aims to comparatively analyze the existing software platforms and state-of-the-art multi-objective optimization algorithms and make a review of what features exist and what features might be included next as further developments in such tools, from a researcher's perspective. ... We decided to select research papers from the Scopus ...
- Particle Swarm Optimization Algorithm and Its Applications: A ... — A swift explanation is presented in this section for the general related studies in the PSO algorithm. Poli et al. [] presented an overview of the great efforts which have given impetus and direction to research in particle swarms, as well as some important new applications and directions.An analysis of IEEE Xplore and Google Scholar citations and publications from 1995 to 2006 were presented ...
5.2 Books and Surveys
- Dynamic Multi-objective Optimization Using Evolutionary Algorithms: A ... — Dynamic Multi-objective Optimization is a challenging research topic since the objective functions, constraints, and problem parameters may change over time. Although dynamic optimization and multi-objective optimization have separately obtained a great interest among many researchers, there are only few studies that have been developed to ...
- Multi-Objective Optimization In Theory and Practice II: Metaheuristic ... — This book is the second part of a presentation on "multi-objective optimization in theory and practice." This book treats static multi-objective optimization programming (MOOP) problems in which an objective or constraint does not vary over time.
- PDF 485538_1_En_Print.indd - Springer — Preface This book focuses on the most well-regarded and recent nature-inspired algorithms capable of solving optimization problems with multiple objectives. First, the book provides preliminaries and essential denitions in multi-objective problems fi and different paradigms to solve them.
- PDF Multi-Objective Optimization using Evolutionary Algorithms — 1 Prologue 1.1 Single and Multi-Objective Optimization 1.1.1 Fundamental Differences 1.2 Two Approaches to Multi-Objective Optimization 1.3 Why Evolutionary? 1.4 Rise of Multi-Objective Evolutionary Algorithms 1.5 Organization of the Book
- Evolutionary Dynamic Multi-objective Optimisation: A Survey — Evolutionary dynamic multi-objective optimisation (EDMO) is a relatively young but rapidly growing area of investigation. EDMO employs evolutionary approaches to handle multi-objective optimisation problems that have time-varying changes in objective functions, constraints, and/or environmental parameters.
- A Systematic Review of Multi-Objective Evolutionary Algorithms ... — This paper aims to comparatively analyze the existing software platforms and state-of-the-art multi-objective optimization algorithms and make a review of what features exist and what features might be included next as further developments in such tools, from a researcher's perspective.
- Multi-objective combinatorial optimization problems and solution ... — In other words, the book presents various multi-objective combinatorial optimization issues that may benefit from different methods in theory and practice.
- PDF Evolutionary Large-Scale Multi-Objective Optimization: A Survey — As a consequence, LSMOPs are much more dificult than small-scale multi-objective optimization problems and large-scale single-objective optimization problems, and hence a variety of new techniques ...
- Evolutionary Dynamic Multi-Objective Optimisation: A Survey — EDMO employs evolutionary approaches to handle multi-objective optimisation problems that have time-varying changes in objective functions, constraints and/or environmental parameters.
- Front Matter - Wiley Online Library — The book closes with a chapter by Vassiliadis and Dounias on the use of a com-putational intelligence multiobjective optimization approach for portfolio optimization.
5.3 Open-Source Tools and Libraries
- A Comprehensive Review of Machine Learning in Multi-objective Optimization — In the real world, it is challenging to calculate a trade-off alternative with traditional classical methods for complex non-linear systems, which always involve multiple conflicting objectives. Such complicated systems urgently desire advanced methods to conquer the multi-objective optimization problems (MOPs). As a promising AI method, the development and application of Machine Learning (ML ...
- pymoo: Multi-objective Optimization in Python — pymoo: An open source framework for multi-objective optimization in Python. It provides not only state of the art single- and multi-objective optimization algorithms but also many more features related to multi-objective optimization such as visualization and decision making.
- Multi-Objective Optimization using Artificial Intelligence Techniques — This book focuses on the most well-regarded and recent nature-inspired algorithms capable of solving optimization problems with multiple objectives. Firstly, it provides preliminaries and essential definitions in multi-objective problems and different paradigms to solve them.
- Pymoo: Multi-Objective Optimization in Python - IEEE Xplore — Since optimization is an inherent part of these research fields, more optimization related frameworks have arisen in the past few years. Only a few of them support optimization of multiple conflicting objectives at a time, but do not provide comprehensive tools for a complete multi-objective optimization task.
- PDF Multi-Objective Optimization using Evolutionary Algorithms — 1 Prologue 1.1 Single and Multi-Objective Optimization 1.1.1 Fundamental Differences 1.2 Two Approaches to Multi-Objective Optimization 1.3 Why Evolutionary? 1.4 Rise of Multi-Objective Evolutionary Algorithms 1.5 Organization of the Book
- Enhancing Multi-Objective Optimization through Machine Learning ... — Typically, this approach involves considering competing objectives simultane-ously within multiobjective optimization tasks, thereby ensuring that the final design solutions strike an optimal balance across diverse performance criteria.
- EvoloPy-FS: An Open-Source Nature-Inspired Optimization ... - Springer — There is always an arm race to build frameworks and libraries that ease and automate this process. In this chapter, an EvoloPy-FS framework is proposed, which is a Python open-source optimization framework that includes several well-regarded swarm intelligence (SI) algorithms. It is geared toward feature selection optimization problems.
- The Exploratory Modeling Workbench: An open source toolkit for ... — This toolkit is implemented in R, has strong support for interactive visualization, and good support for working with BORG (Hadka and Reed, 2013) and other state of the art multi-objective optimization algorithms.
- (PDF) pymoo: Multi-objective Optimization in Python - ResearchGate — Only a few of them support optimization of multiple conflicting objectives at a time, but do not provide comprehensive tools for a complete multi-objective optimization task.
- mealpy · PyPI — MEALPY is the largest python library in the world for most of the cutting-edge meta-heuristic algorithms (nature-inspired algorithms, black-box optimization, global search optimizers, iterative learning algorithms, continuous optimization, derivative free optimization, gradient free optimization, zeroth order optimization, stochastic search ...